ENGINEERING LAB & HARDWARE ECOSYSTEM.
The REVEROB Engineering Lab is the hardware verification backbone where embedded AI computers, optical/thermal cameras, LiDAR and environmental sensors, and mechatronic driver boards are bench-tested and integrated into robotic prototypes.
Raspberry Pi 5
Primary single-board computer in the VELTRON UNIT X1 core architecture. Executes Sony IMX477 CSI camera streaming, sensor telemetry aggregation, and REVEROB OS node communication.
Quad-Core Cortex-A76 @ 2.4GHz • Dual 4-Lane MIPI CSI/DSI • PCIe 2.0 • I2C/UART/SPI
NVIDIA Jetson Orin Nano
Higher-tier Edge AI compute target architecture designated for high-FPS YOLOv8 inference, multi-camera fusion, and 3D LiDAR SLAM workloads.
1024-Core NVIDIA Ampere GPU • 6-Core Arm Cortex-A78AE • Up to 40 TOPS AI • MIPI CSI-2
Raspberry Pi Compute Module 5 (CM5)
Industrial system-on-module architecture evaluated for compact custom REVEROB carrier PCBs and next-generation embedded field nodes.
BCM2712 SoC • High-Density Board-to-Board Connectors • Onboard eMMC • PCIe Gen 2
ESP32 Dual-Core MCU
Actively deployed in the TFT ILI9341 Embedded Smart Assistant Terminal prototype, wireless telemetry sub-nodes, and auxiliary actuator control.
Xtensa Dual-Core LX6 @ 240MHz • Wi-Fi 802.11 b/g/n • Bluetooth BLE • SPI/I2C/UART/PWM
Sipeed Maixduino K210 (RISC-V AI)
RISC-V development board with dedicated KPU neural accelerator maintained in lab inventory for ultra-low-power edge vision experimentation.
Dual-Core 64-Bit RISC-V @ 400MHz + KPU (Neural Network Processor) + ESP32 Wi-Fi Module
Sony IMX477 12.3MP CSI Camera
High-resolution primary optical camera actively integrated into the VELTRON UNIT X1 sensor mast and SBC computer vision testbench.
12.3 Megapixel CMOS • 1/2.3" Sensor • MIPI CSI-2 Ribbon Interface • C/CS-Mount Lens Support
Computer Vision Systems (UC-392 CSI/HDMI + C-Mount Lens Rig)
Bench-verified optical camera assembly combining the UC-392 CSI/HDMI adapter board with an adjustable industrial C-mount lens for long-run signal integrity.
UC-392 Rev.B CSI-to-HDMI Adapter PCB + Industrial C-Mount Manual Iris/Focus Lens
YOLOv8 + Kalman Filter Vision Pipeline
Real-time computer vision software pipeline performing YOLOv8 object classification, Kalman Filter trajectory tracking, and HUD telemetry rendering in REVEROB OS.
YOLOv8 Object Detection • Kalman Filter State Estimation • Thermal-Optical Overlay HUD
AMG8833 8x8 IR Thermal Array
Core sensor in the VELTRON UNIT X1 payload suite used to detect heat signatures, overheating equipment, and thermal anomalies through smoke.
8x8 (64-Pixel) Infrared Thermopile Array • I2C Interface • 0°C to 80°C Measurement Range
TFmini-S Single-Point ToF LiDAR
Optical Time-of-Flight LiDAR module in VELTRON’s sensor architecture providing high-frequency forward distance ranging and collision threshold alerts.
Time-of-Flight (ToF) Optical Ranging • 0.1m – 12m Range • UART / I2C • Up to 1000Hz
MQ-2 Combustible Gas & Smoke Sensor
Monitors combustible gas leaks (LPG, methane, hydrogen) and smoke concentration during hazardous field reconnaissance, alerting the REVEROB OS console.
SnO2 Semiconductor Chemiresistor • Analog + Digital Threshold Output • LPG/Propane/H2/Smoke
HC-SR04 Ultrasonic Distance Sensor
Bench-verified in the multi-floor Arduino Smart Elevator Tower prototype for cabin height positioning and proximity safety checks.
40kHz Ultrasonic Pulse Ranging • 2cm – 400cm Range • Digital Trigger/Echo GPIO
IMU (6-DOF / 9-DOF Inertial Measurement Unit)
Measures chassis pitch, roll, and yaw angular velocity on uneven terrain to support stability monitoring and inertial dead-reckoning.
3-Axis Accelerometer + 3-Axis Gyroscope (+ Magnetometer) • I2C / SPI High-Speed Bus
Rotary & Motor Shaft Encoder Systems
Provides closed-loop shaft RPM measurement, linear travel odometry, and precise mechanical position feedback across drivetrain and test rigs.
Quadrature Incremental A/B Phase Pulse Output • Hardware Interrupt GPIO Counting
NRF24L01+ 2.4GHz RF Transceiver
Provides deterministic, low-latency 2.4GHz command and telemetry communication between the custom handheld controller and robotic test platforms.
2.4GHz ISM Band GFSK Transceiver • SPI Interface • Up to 2Mbps Air Data Rate • PA+LNA Support
Arduino Uno (ATmega328P)
Serves as the deterministic 5V real-time controller for the Smart Elevator Tower prototype, L298N motor drives, and the micro-turbojet ignition testbench.
ATmega328P 8-Bit AVR @ 16MHz • 14 Digital I/O (6 PWM) • 6 Analog Inputs • UART/I2C/SPI
OLED SSD1106 / SH1106 128x64 Display
High-contrast micro display integrated into embedded nodes and controllers to display battery voltage, RF link status, and live sensor readings.
1.3" 128x64 Monochrome OLED • I2C / SPI Interface • High-Contrast Self-Luminous Pixels
TFT ILI9341 & 7-Inch 1024x600 IPS (RTD2660H)
ILI9341 drives the Embedded Smart Assistant UI, while the 7-inch 1024x600 IPS panel with RTD2660H driver board powers the portable SBC vision and command bench.
2.4"/2.8" SPI Color TFT (ILI9341) + 7" 1024x600 IPS LCD with RTD2660H HDMI Driver PCB
SG90 & Micro Servo Actuators
Provides angular position actuation for sensor pan-tilt mounts, elevator door mechanisms, and small-scale kinematic joint prototypes.
50Hz PWM Position Control • 180° Rotational Arc • 4.8V–6.0V Operating Voltage
NEMA Stepper Motors (NEMA 17 Series)
Employed across high-precision rotary turrets, linear rails, and additive manufacturing motion systems requiring high holding torque and open-loop step accuracy.
1.8° Step Angle (200 Steps/Rev) • Bipolar 2-Phase • Microstepping Driver Compatible
L298N Dual H-Bridge Motor Driver
Heatsink-equipped dual H-bridge power electronics module driving bidirectional DC gearmotors and stepper coils across mechatronic prototypes.
Dual Full-Bridge Driver • Up to 46V / 2A per Channel • PWM Speed + Direction Logic
WS2812B Addressable RGB LED Arrays
Individually addressable RGB LED strips signaling autonomous mode, manual override, fault states, or gas hazard alerts in the field.
Single-Wire NZR Digital Protocol • Individually Addressable 24-Bit RGB • 5V DC
Lab Workbench & Physical Hardware Verification Gallery
These authentic archive photographs document REVEROB’s physical bench setups—including CSI camera rigs, 7-inch IPS driver PCB tests, the custom VELTRON handheld controller, the ESP32 smart assistant terminal, the Arduino elevator tower, and the 3D printing line.
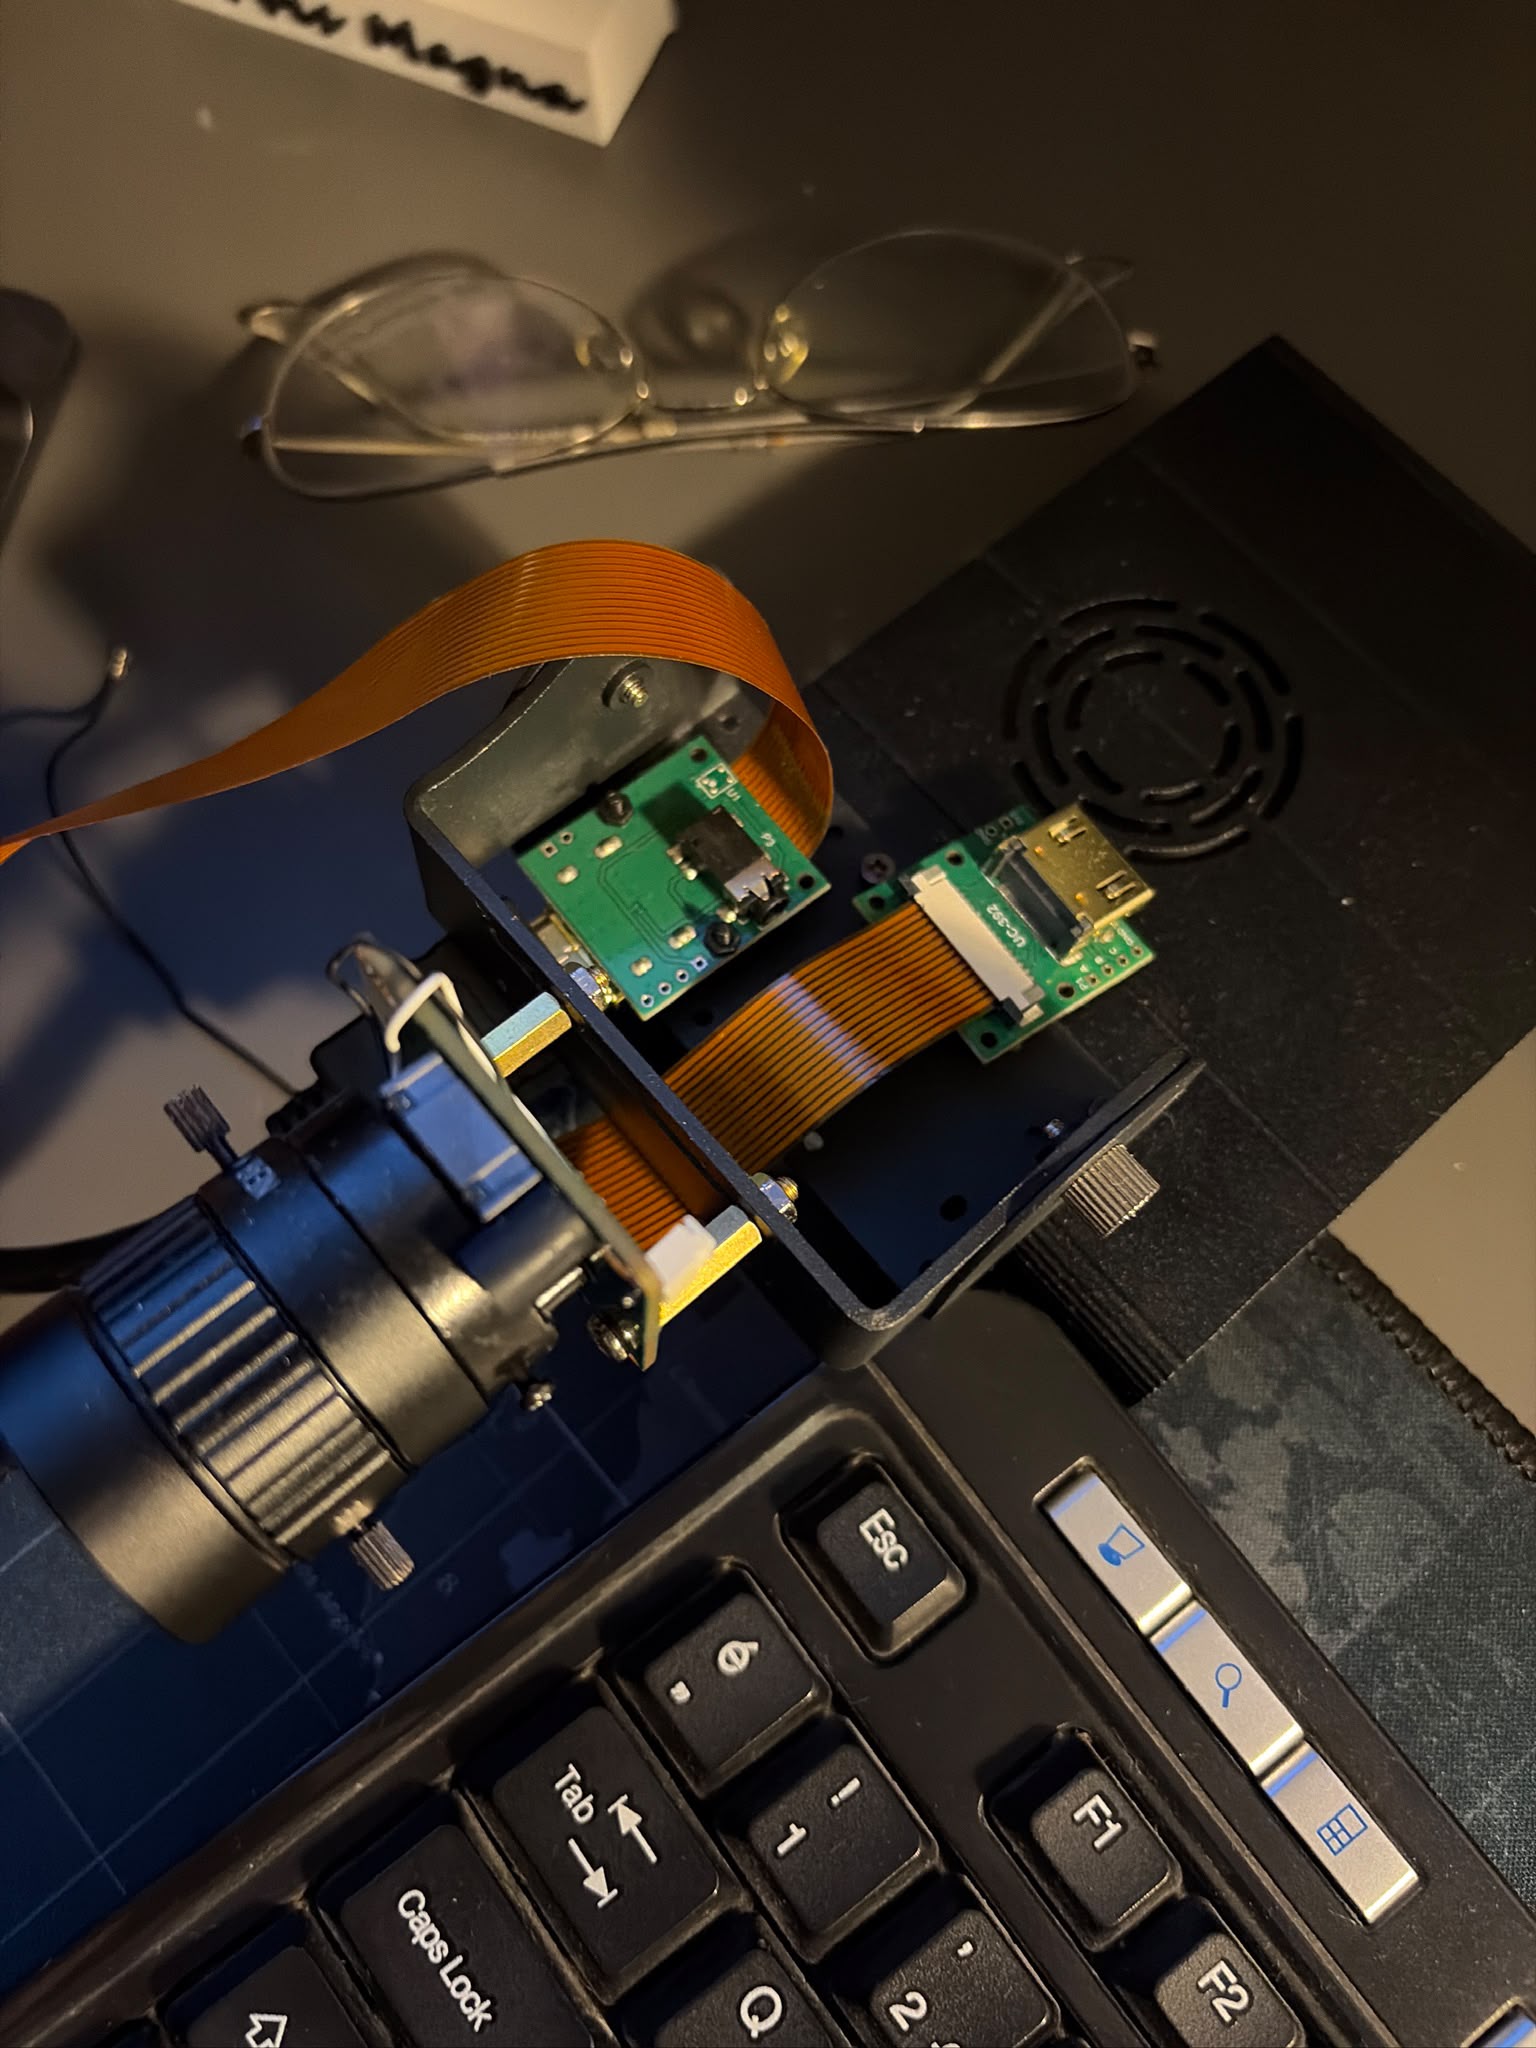
UC-392 CSI Camera Module & C-Mount Lens Assembly
Mechanical and electronic integration of the industrial C-mount lens, CSI camera sensor, and UC-392 adapter PCB.
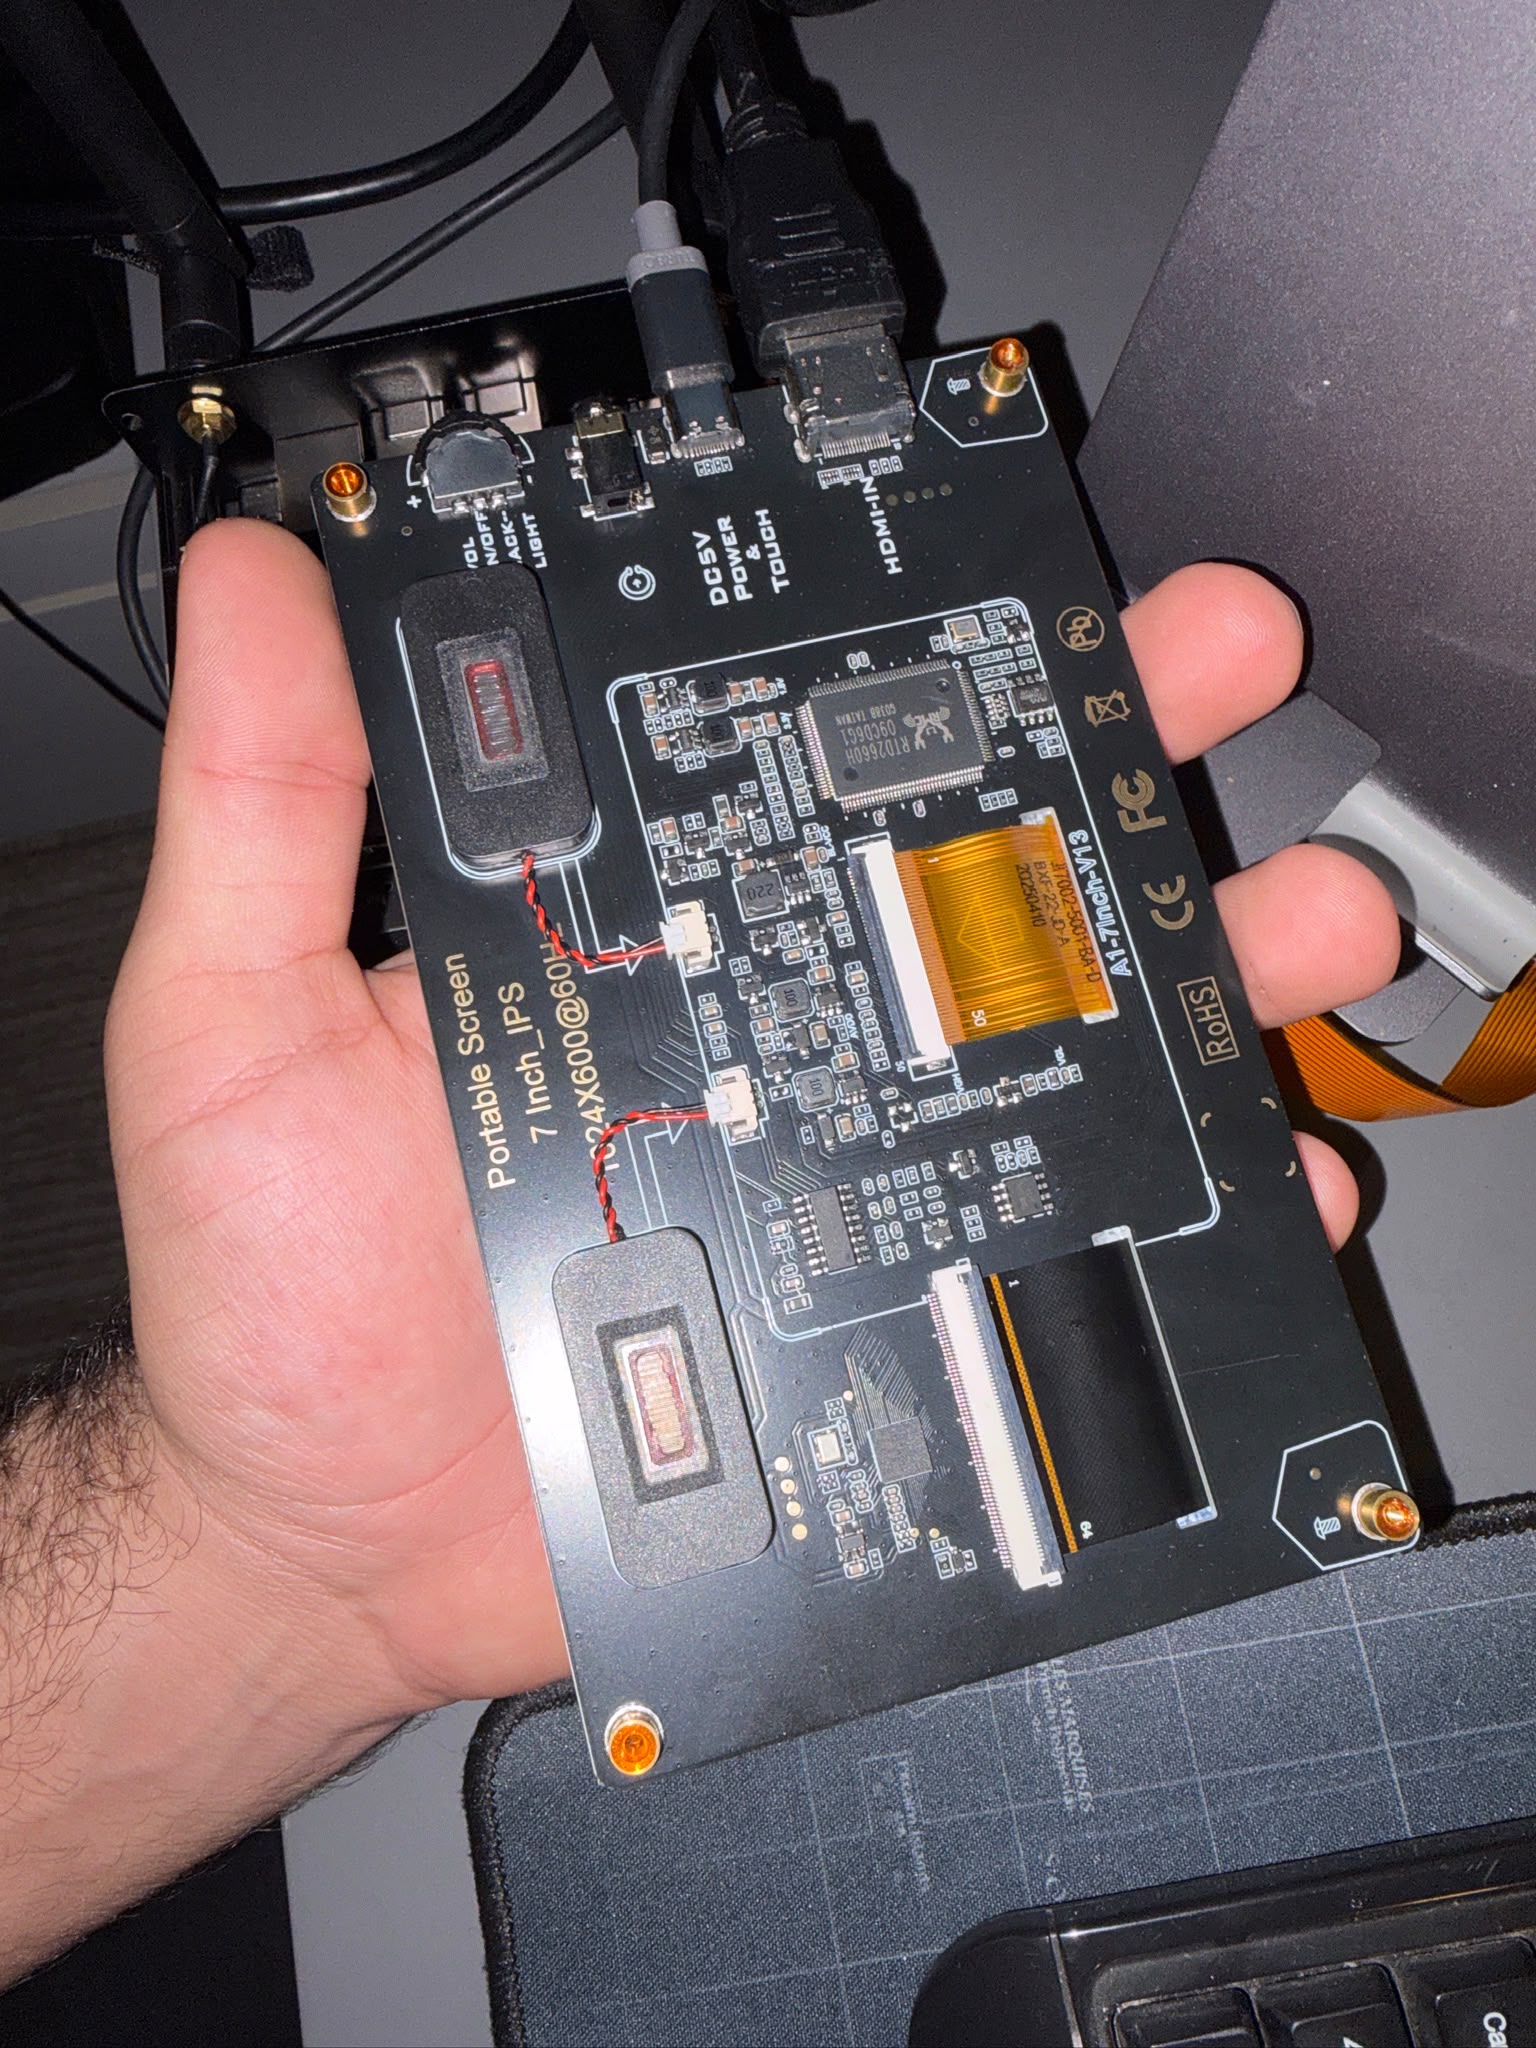
7-Inch 1024x600 IPS Display & RTD2660H Driver PCB
Display panel and LVDS/HDMI driver circuitry used for portable command stations and vision verification.
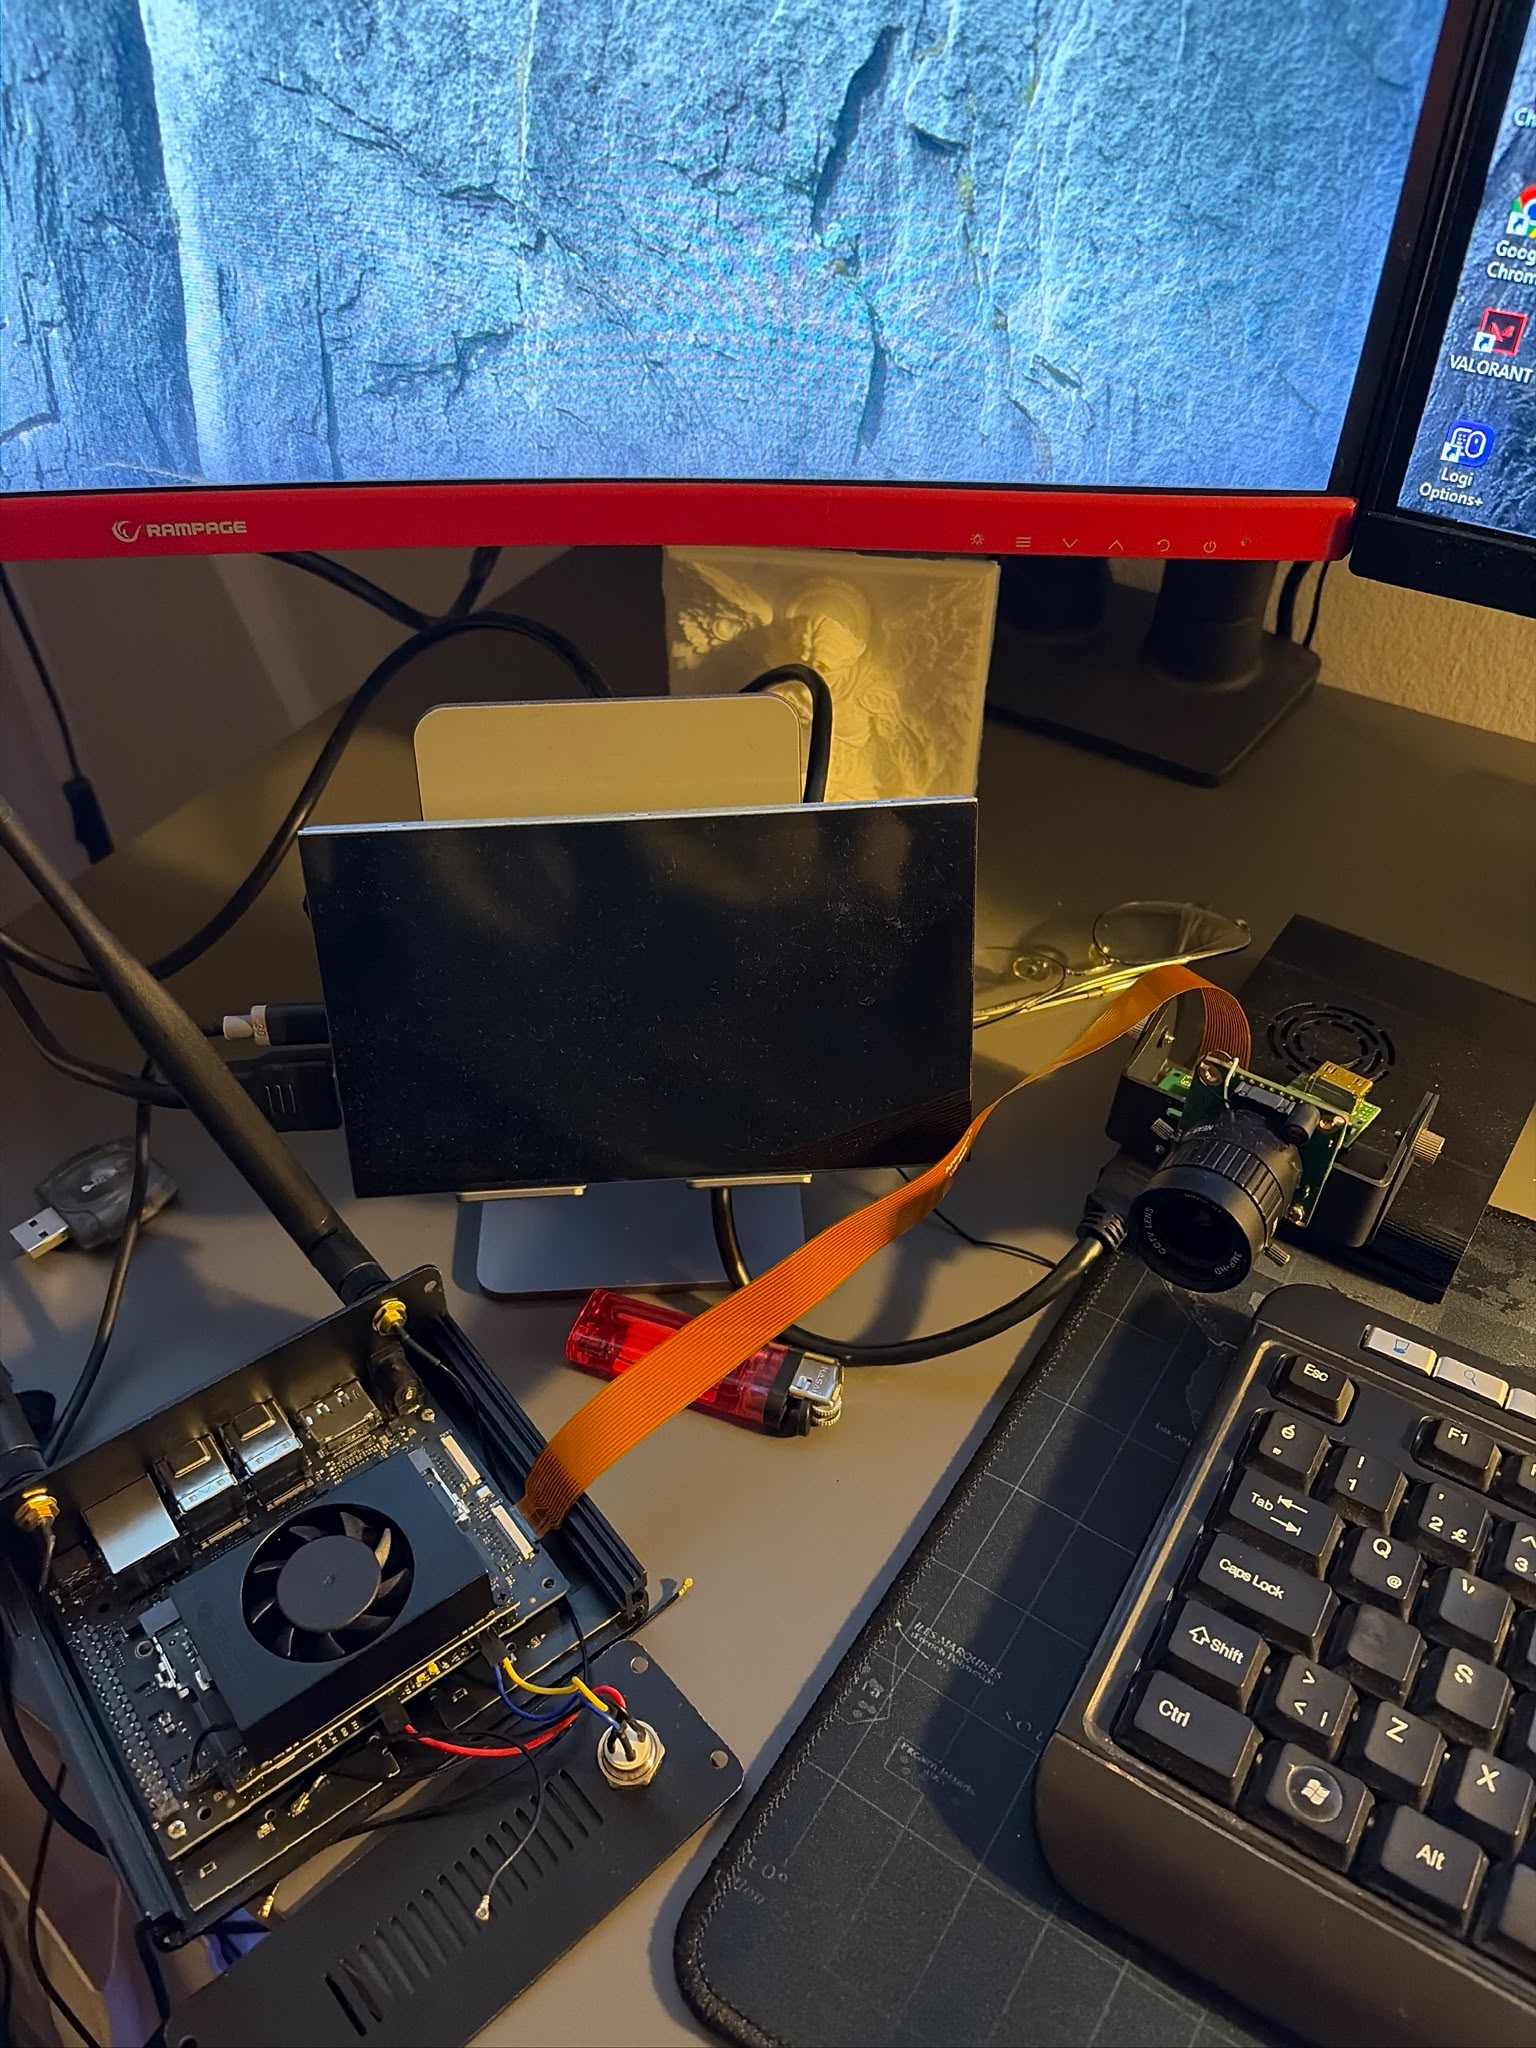
SBC + CSI Camera + IPS Display Live Vision Testbench
Real-time latency and optical clarity testing of the SBC camera pipeline rendered on the 7-inch IPS screen.
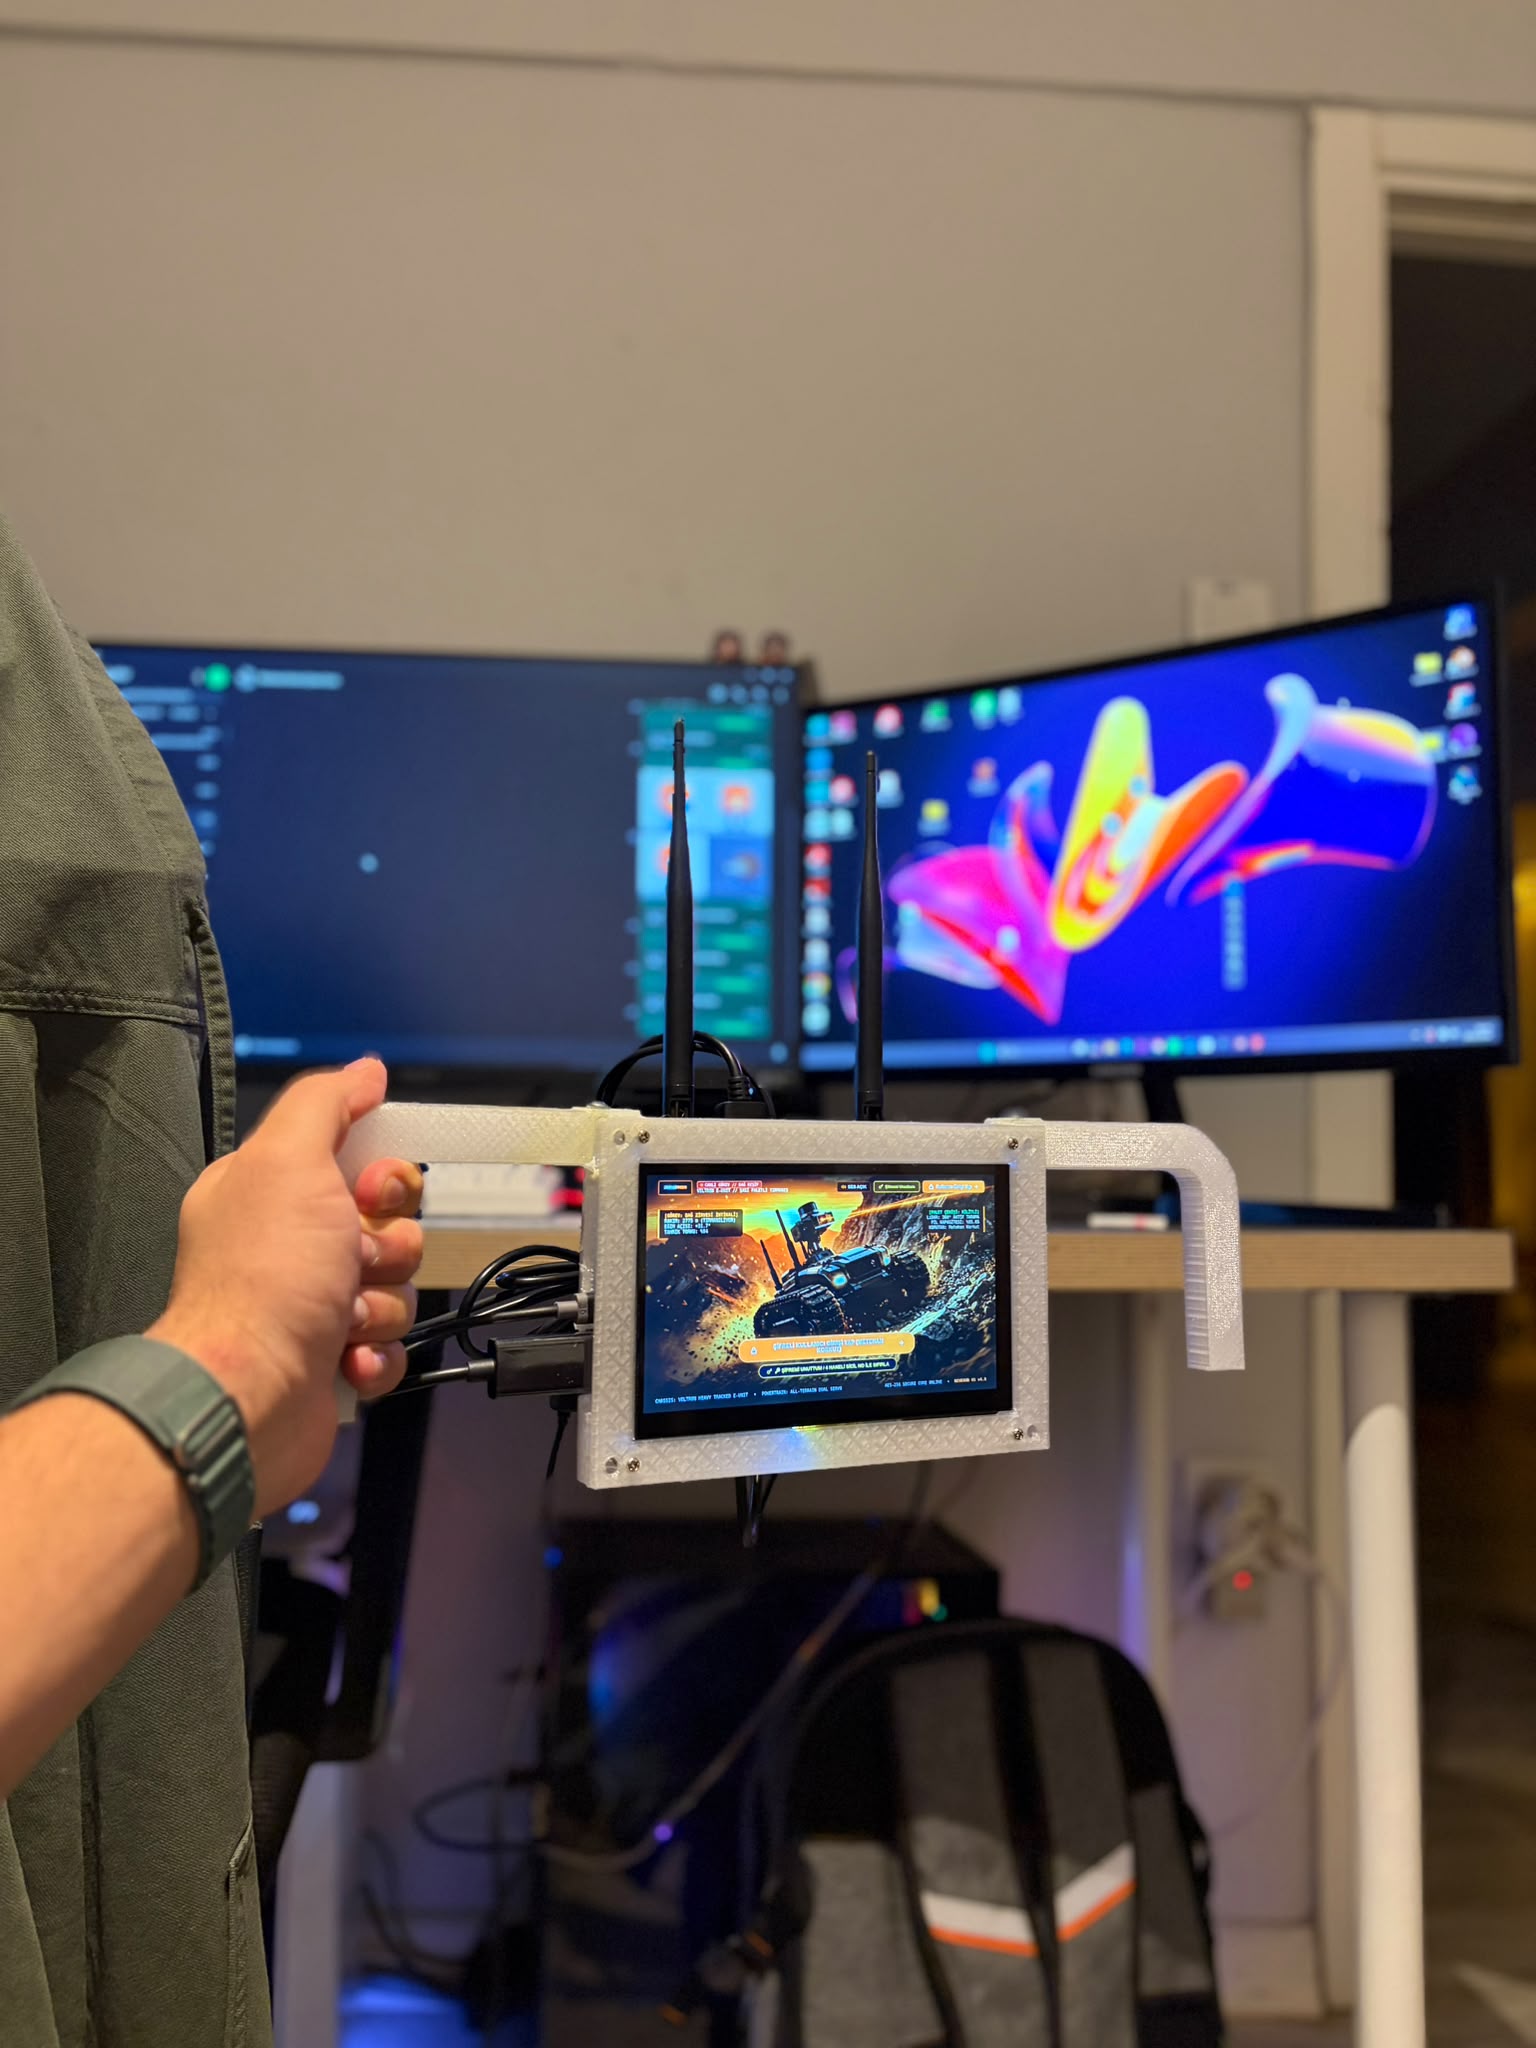
VELTRON Custom Handheld Controller Prototype — Front View
Custom field controller featuring dual analog joysticks, tactile switches, and a 3D-printed ergonomic enclosure.
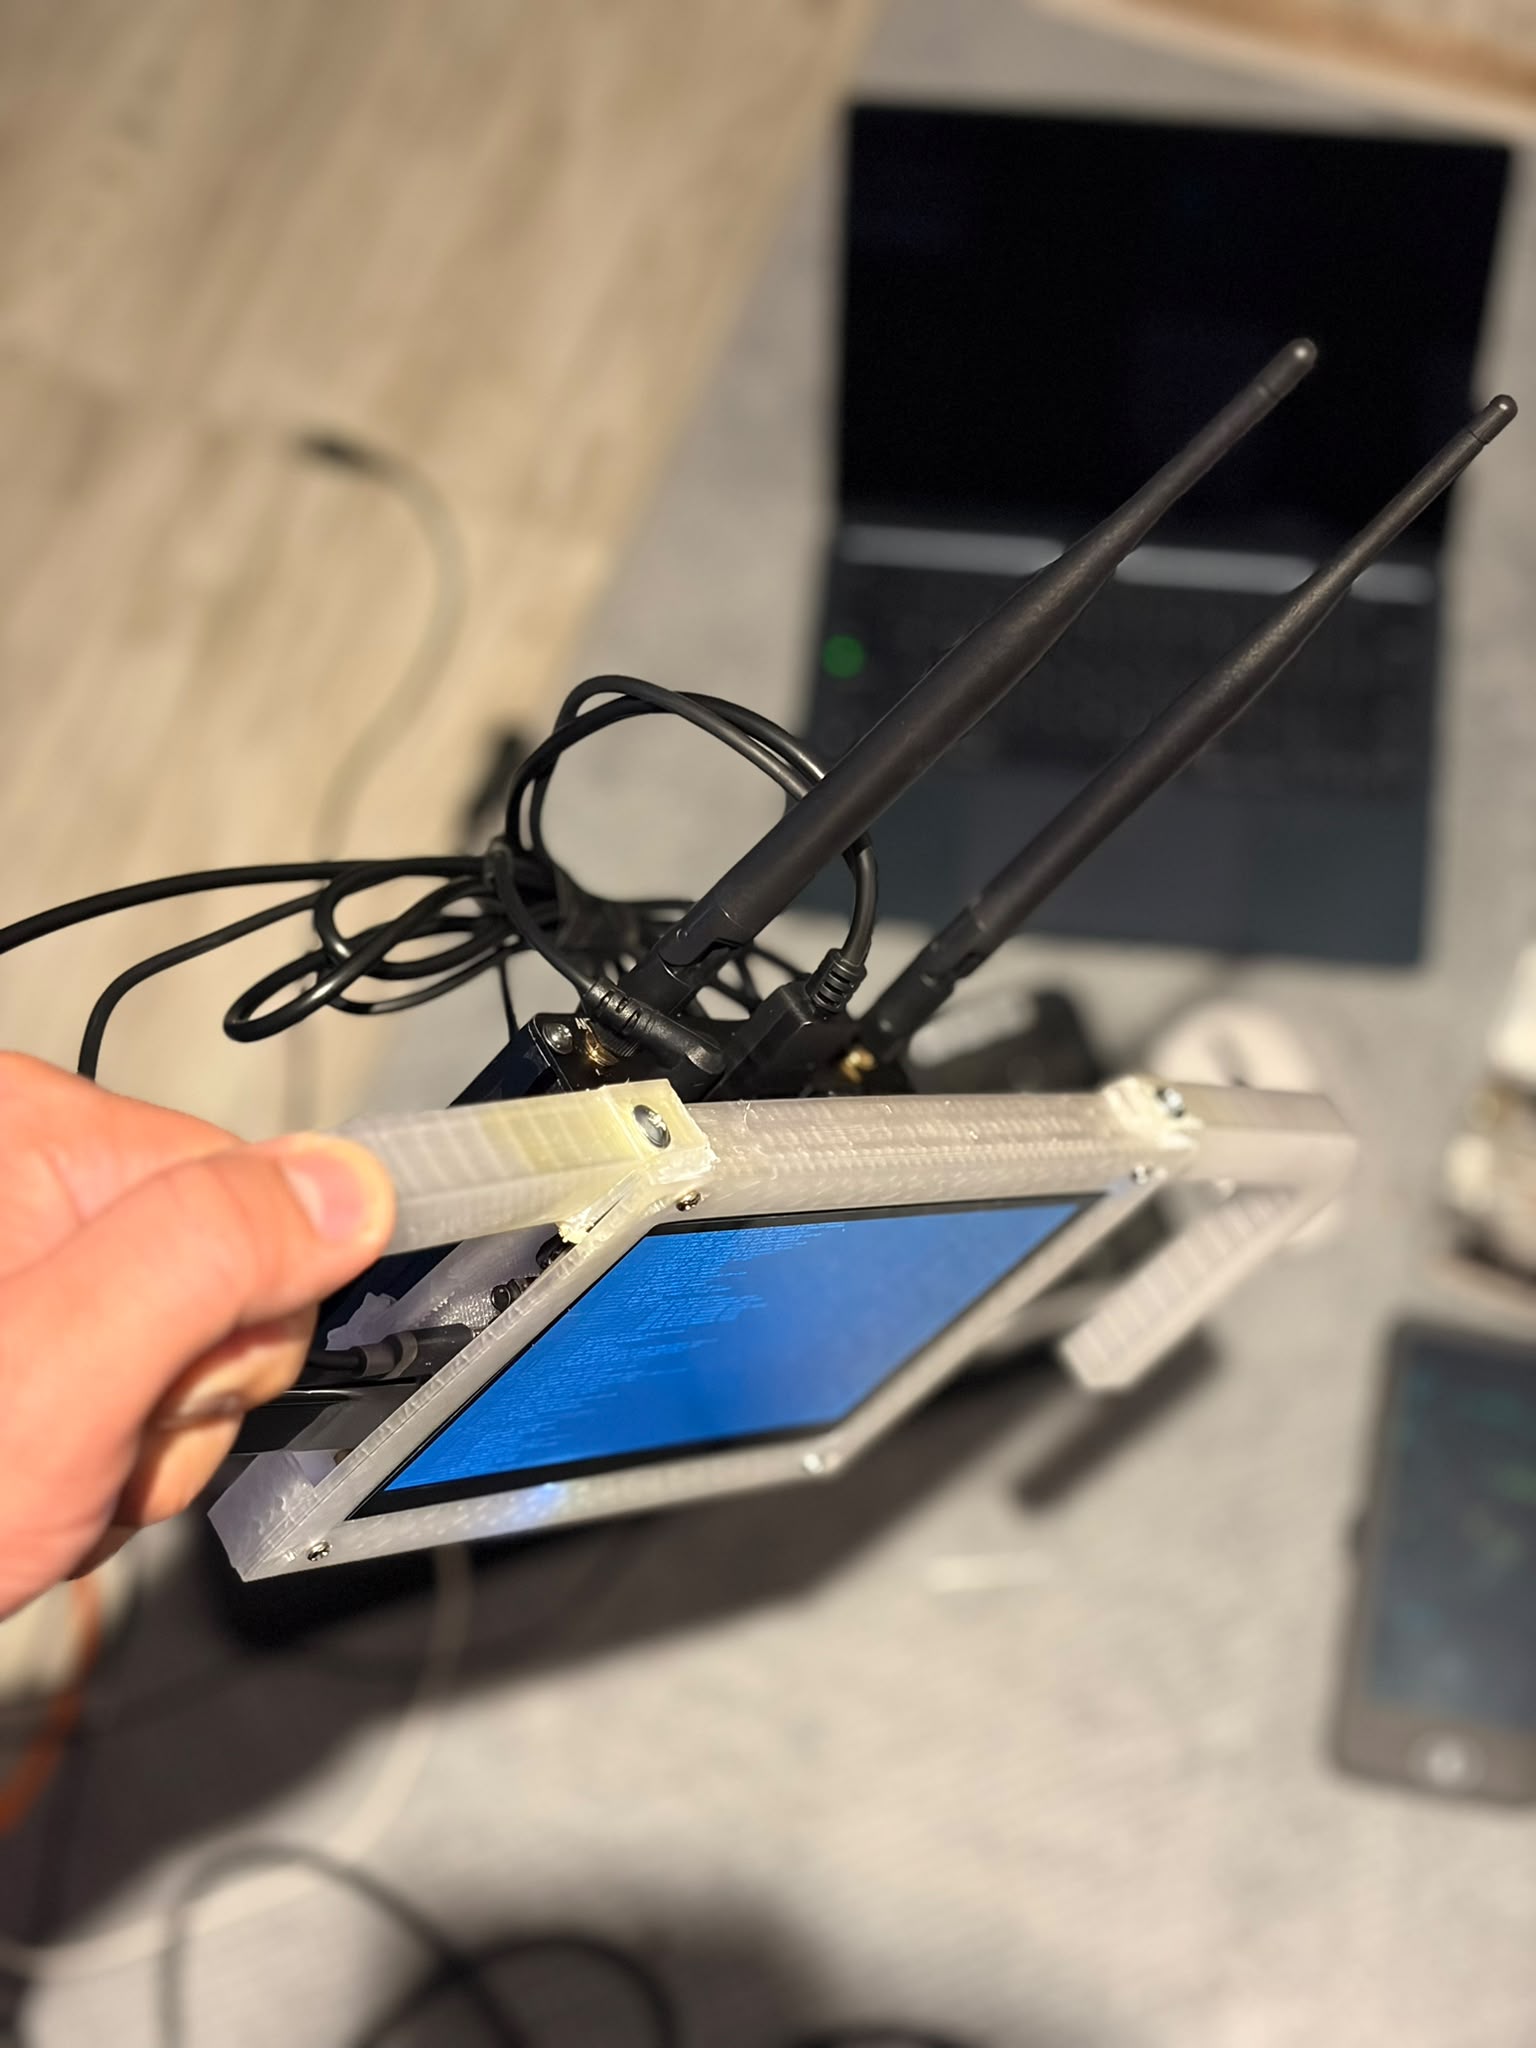
VELTRON Handheld Controller — Top Angle & Trigger Layout
Upper trigger and grip geometry engineered for precise operator maneuvering during field teleoperation.
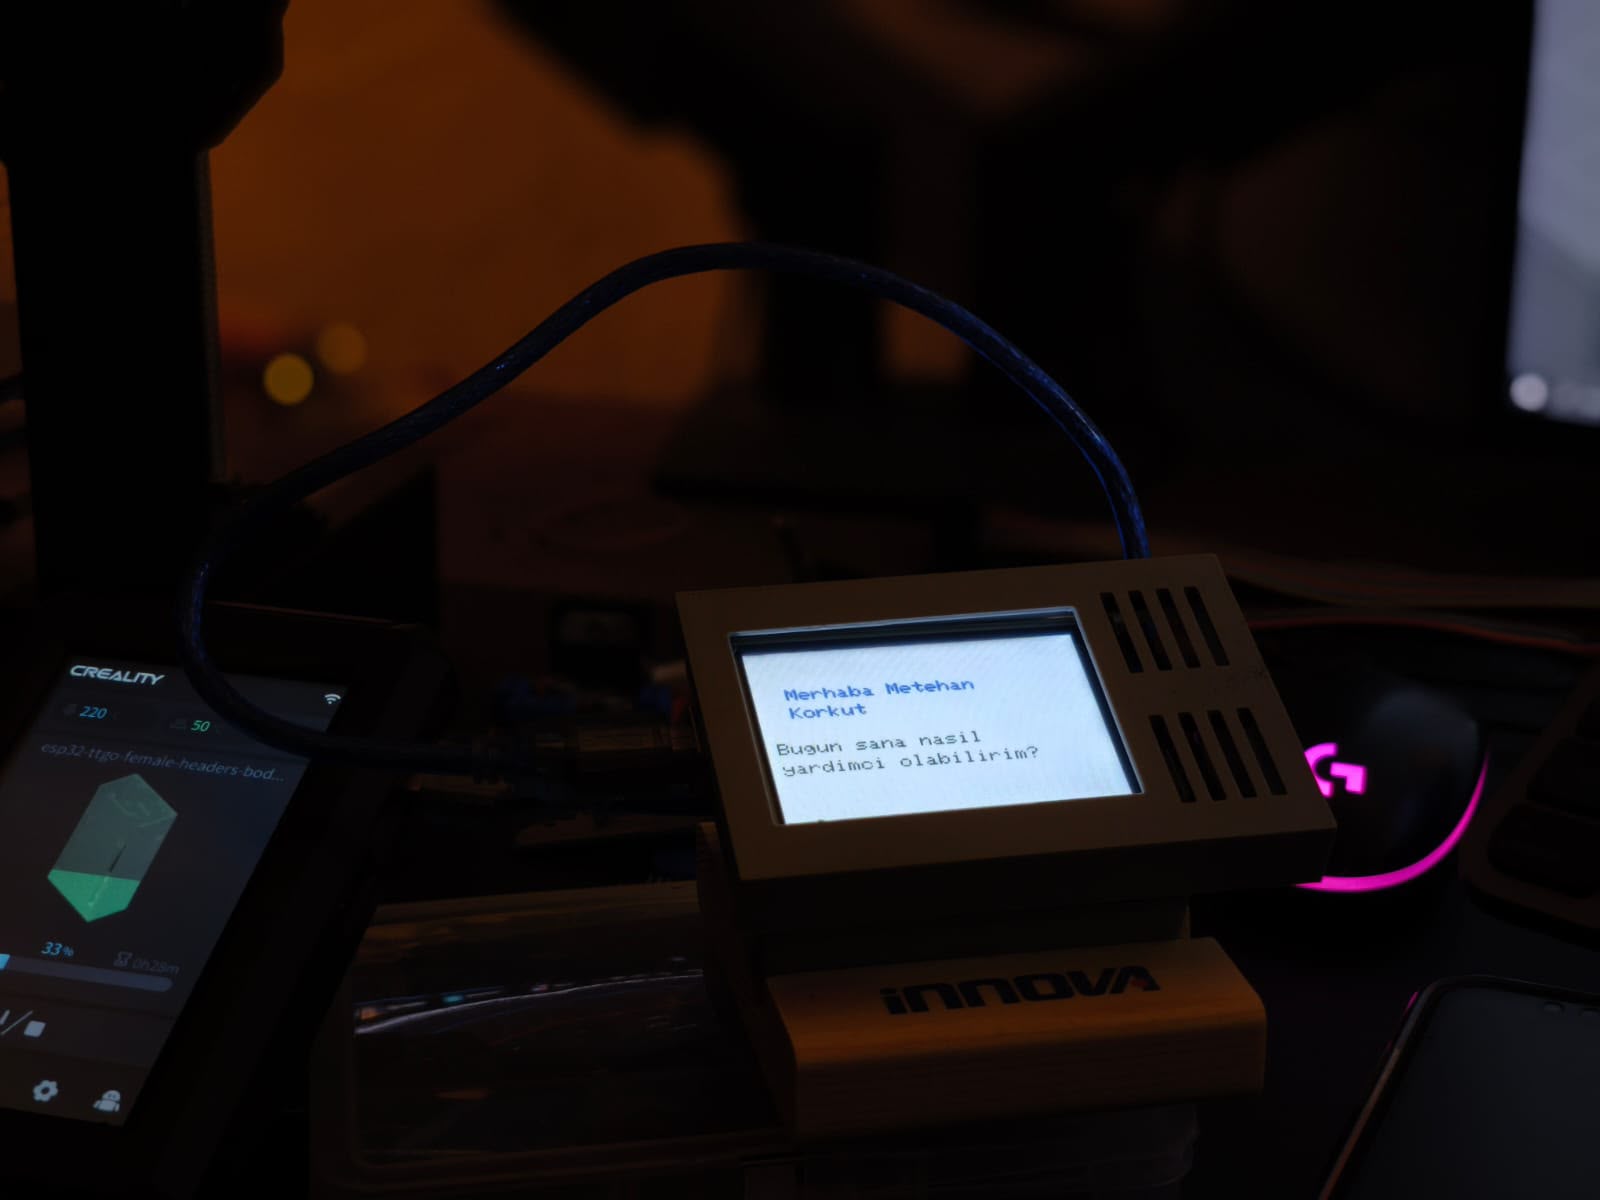
ESP32 & TFT Embedded Smart Assistant Terminal
Custom 3D-printed desktop embedded interaction unit running the "Hello I’m Your Assistant" TFT interface.
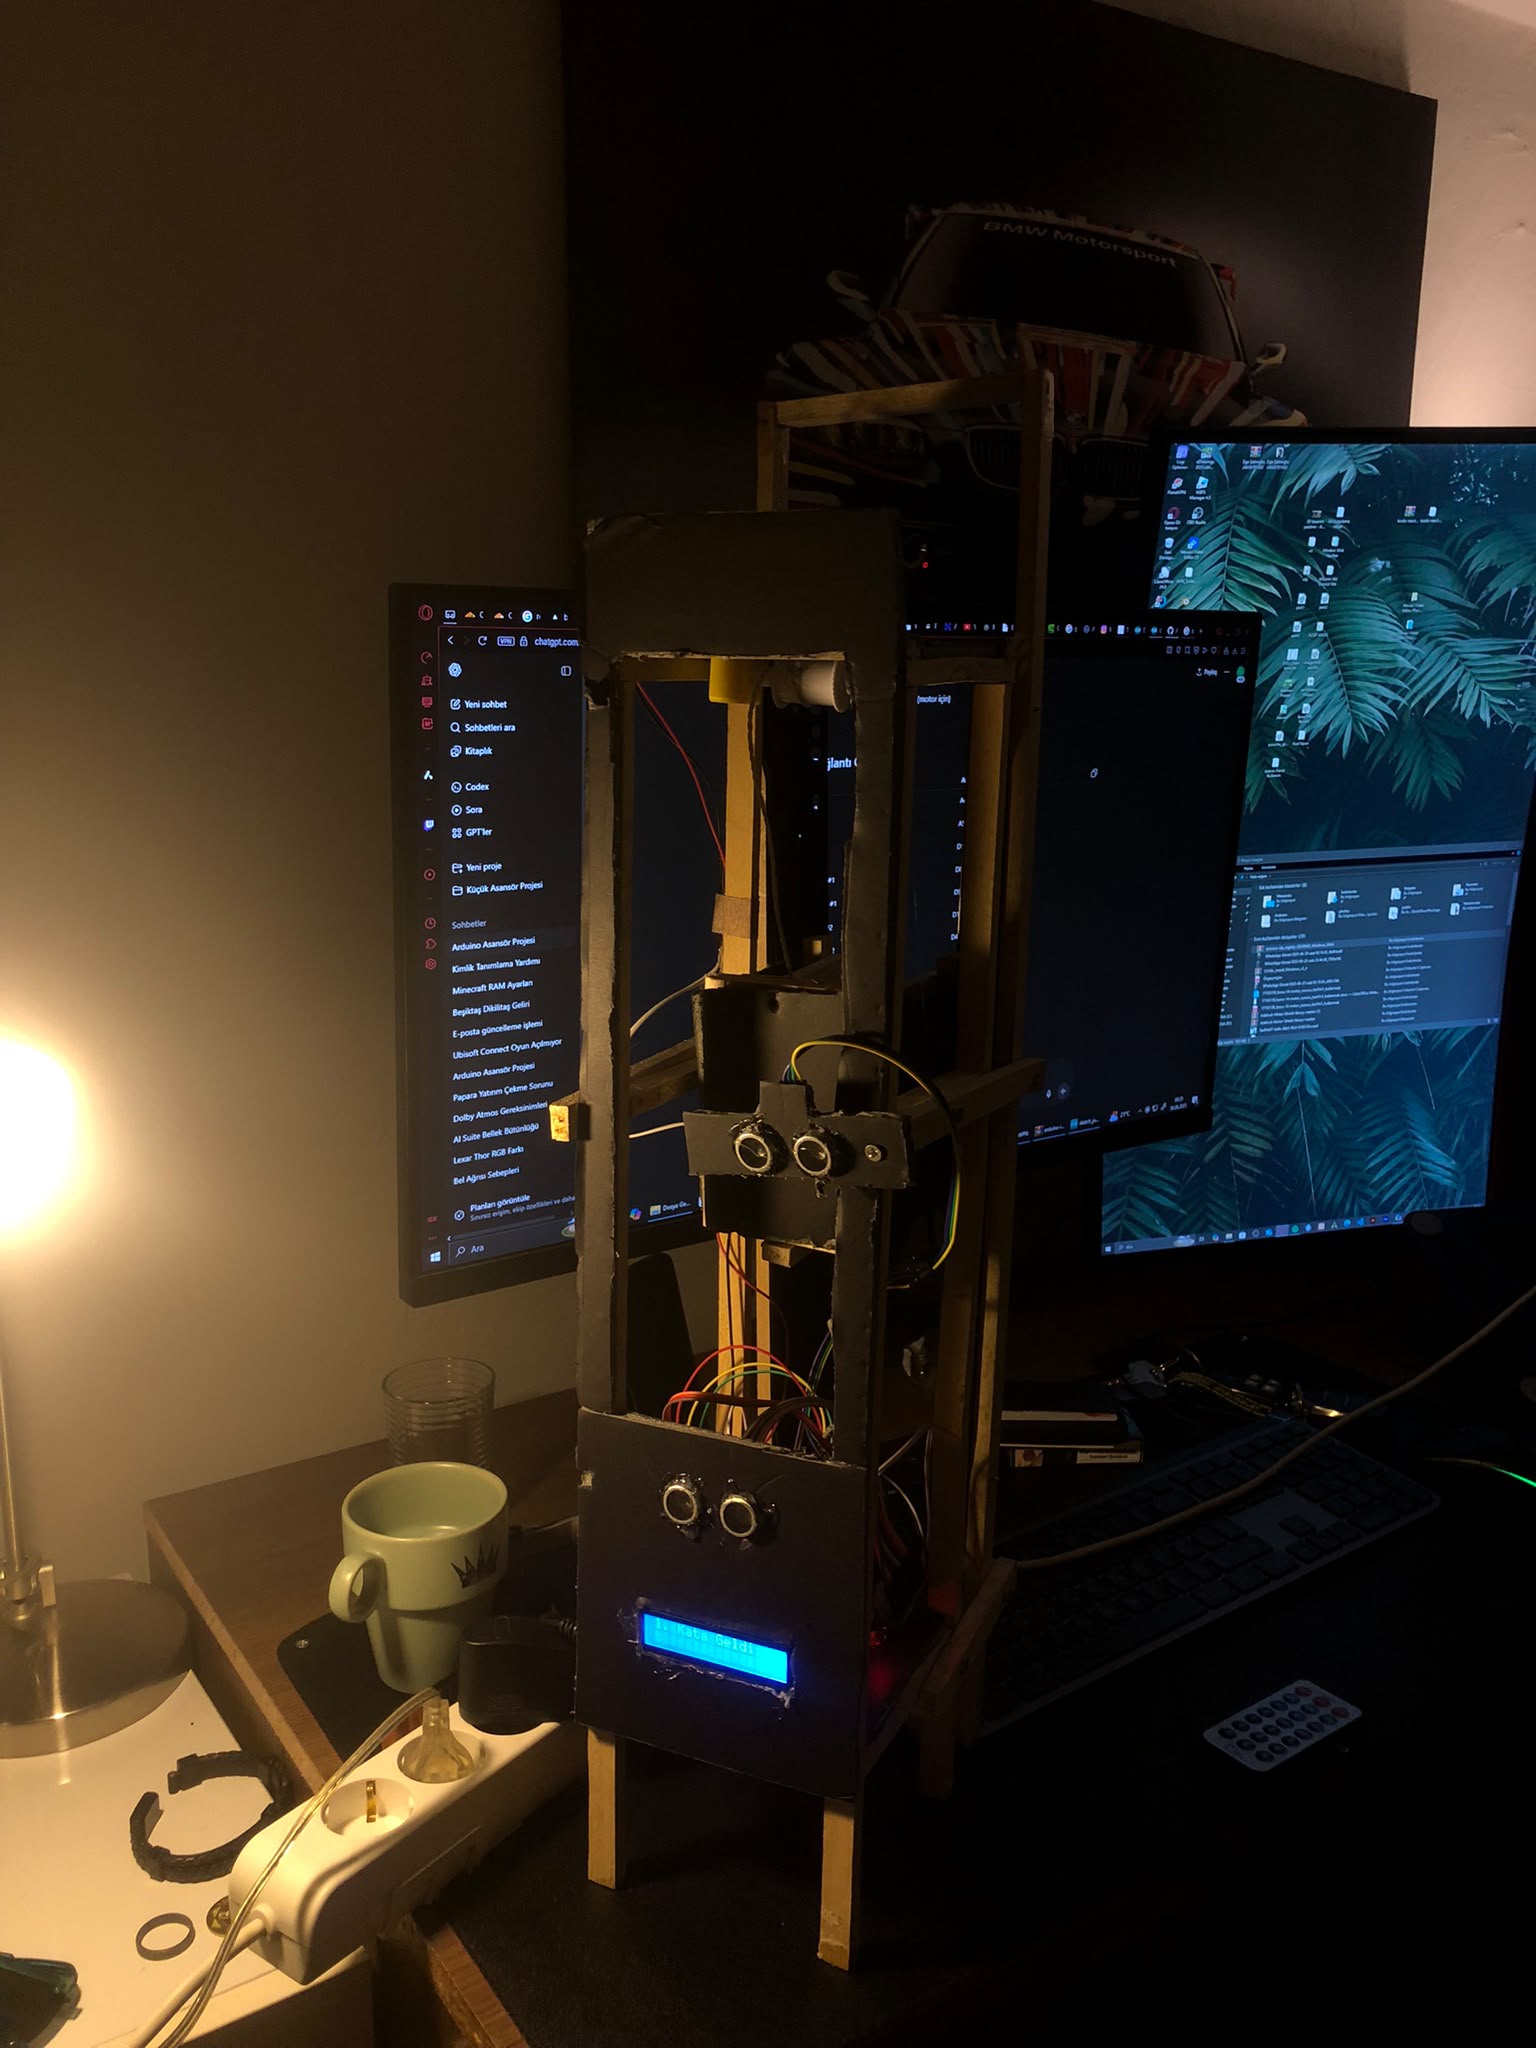
Arduino-Based Mechatronic Smart Elevator Prototype Tower
Multi-floor closed-loop mechatronics test tower integrating HC-SR04 ultrasonic ranging, motor drivers, and vertical guide rails.
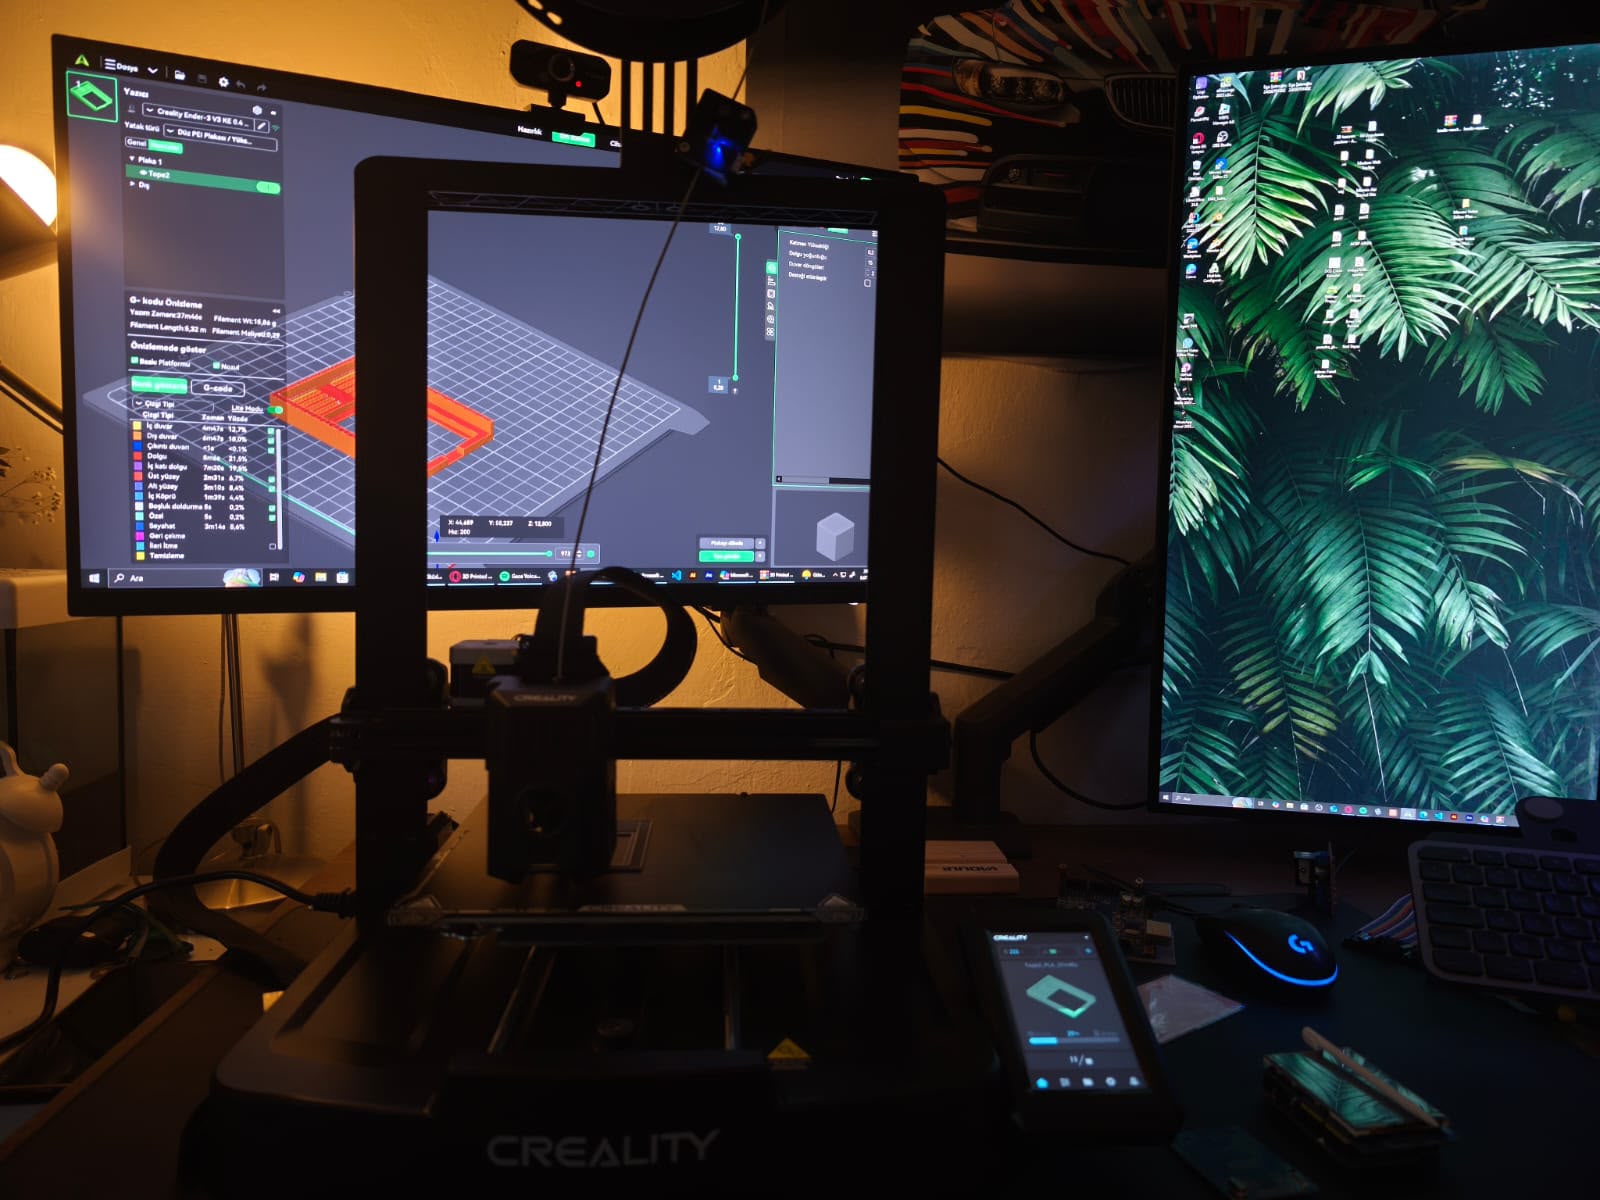
FORGELAB 3D — Creality Ender-3 V3 KE Additive Manufacturing Setup
High-speed FDM 3D printing station fabricating structural robot brackets, sensor mounts, and controller enclosures.