INTEGRATED ROBOTICS & TECHNOLOGY DOMAINS.
REVEROB unites mechanical chassis engineering, computer vision (YOLOv8), autonomous navigation, embedded system architecture, central command software (REVEROB OS), and experimental R&D into a single vertically integrated technology stack.
ROBOTICS ENGINEERING
Mechanical Design, 6061 Aluminum Chassis Engineering, Mobile Tracked & 12-DOF Quadruped Platforms
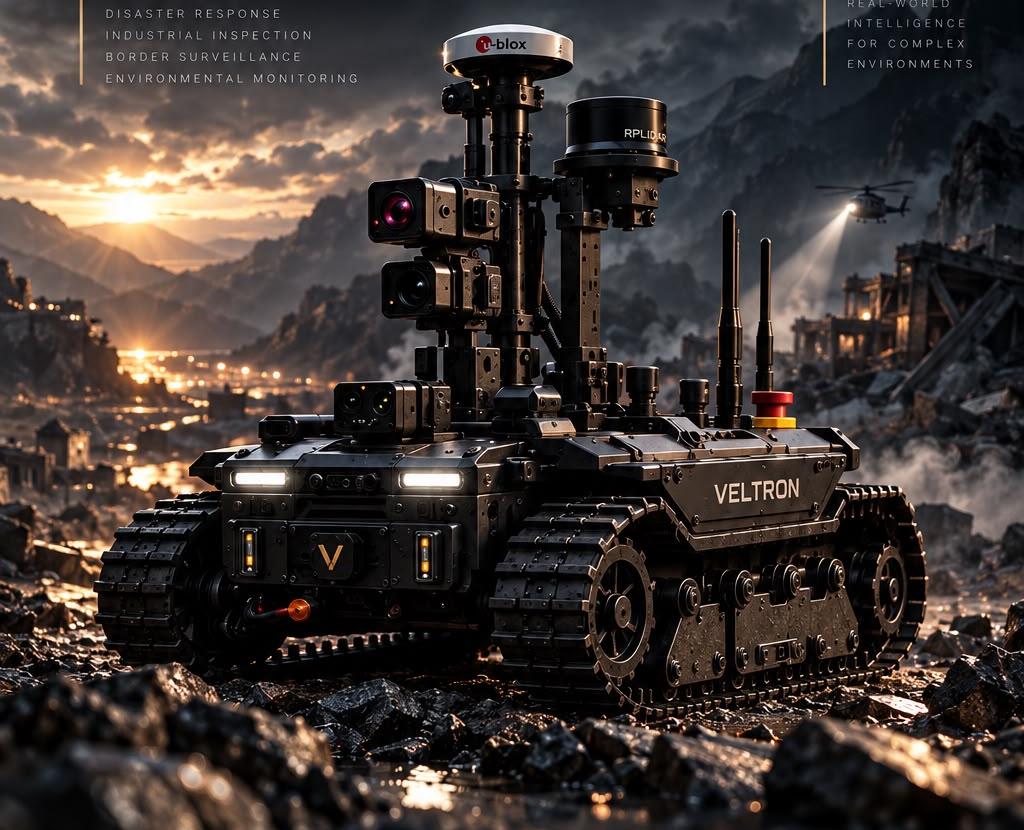
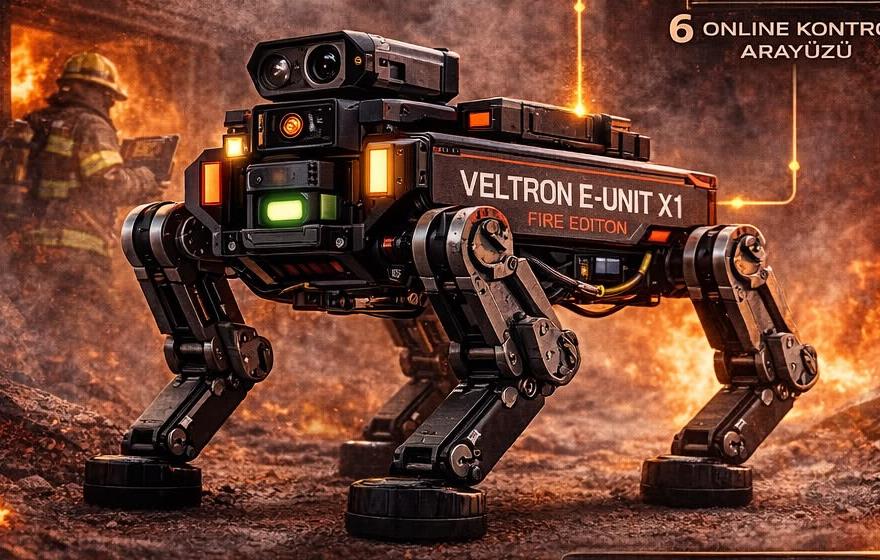
REVEROB Robotics Engineering encompasses the mechanical, structural, and electromechanical design of modular tracked platforms (VELTRON UNIT X1) and 12-DOF quadruped locomotion architectures built for challenging field environments.
- Chassis Structure
- 6061 Aluminum Frame + Modular Polymer/Composite Panels
- Locomotion Configurations
- High-Traction Tracked Drive & 12-DOF Quadruped Leg Kinematics
- Sensor Mast Integration
- Optical Camera, Thermal Array, LiDAR & Gas Sensor Payload Mast
- Actuation & Drive
- High-Torque DC/Brushless Drives, NEMA Stepper & Servo Mechanisms
// VERIFIED ENGINEERING CAPABILITIES
- 3D parametric CAD modeling and structural load distribution analysis
- Tracked suspension geometry and differential skid-steer control
- Modular payload mounting interfaces and rapid-swap architecture
- Field response and firefighting/reconnaissance (Fire Edition) hardware variants
ARTIFICIAL INTELLIGENCE
Computer Vision, YOLOv8 Real-Time Object Detection, Kalman Filter Tracking & Thermal Fusion
The REVEROB AI layer transforms raw optical and thermal sensor streams into real-time scene perception. YOLOv8 object detection paired with Kalman Filter multi-target tracking delivers immediate situational awareness to field operators.
- Object Detection Engine
- YOLOv8 Real-Time Neural Inference Pipeline
- Target Tracking Algorithm
- Kalman Filter State Estimation & Multi-Target Trajectory Tracking
- Thermal & Optical Fusion
- Sony IMX477 RGB + AMG8833 IR Thermal Hotspot Mapping
- Edge AI Target Compute
- NVIDIA Jetson Orin Nano / Sipeed Maixduino K210 / RPi 5
// VERIFIED ENGINEERING CAPABILITIES
- Real-time classification and bounding-box overlay on low-latency CSI camera streams
- Thermal anomaly and heat-source localization in smoke or low-visibility environments
- Target velocity and heading vector estimation via Kalman Filtering
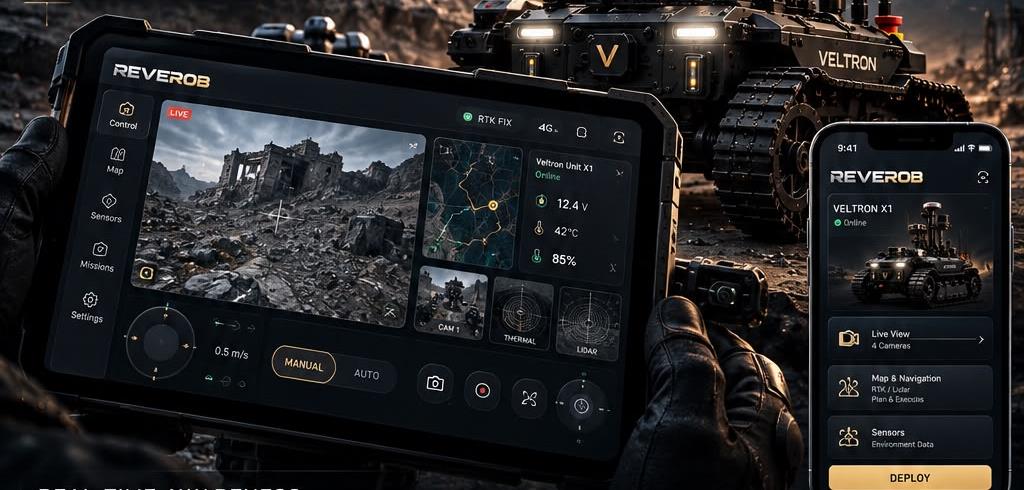
- Live AI telemetry HUD overlay streaming directly to REVEROB OS command displays
AUTONOMOUS SYSTEMS
Navigation, 3D LiDAR Point-Cloud Mapping, Waypoint Mission Coordination & Obstacle Avoidance
The Autonomous Systems domain covers spatial localization in unstructured environments, 3D LiDAR point-cloud reconstruction, waypoint-driven mission coordination, RTK GNSS telemetry, and obstacle avoidance research.
- Spatial Mapping
- 3D LiDAR Point-Cloud Reconstruction & TFmini-S Ranging
- Localization & Navigation
- RTK GNSS Telemetry Architecture + 6-DOF/9-DOF IMU Inertial Fusion
- Mission Coordination
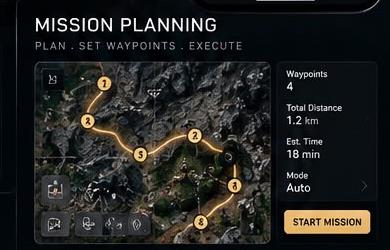
- REVEROB OS Multi-Waypoint Route Planning & Autonomous Patrol
- Proximity Safety
- ToF LiDAR + Ultrasonic Distance Threshold Collision Prevention
// VERIFIED ENGINEERING CAPABILITIES
- 3D point-cloud visualization of indoor corridors and outdoor terrain topography
- Interactive map waypoint assignment and real-time telemetry feedback
- Wheel/track encoder odometry fused with IMU attitude and heading estimation
- Automatic safety braking and reactive path adjustment at critical proximity thresholds
EMBEDDED SYSTEMS
NVIDIA Jetson Orin Nano, Raspberry Pi 5, CM5, ESP32, Maixduino K210 & Sensor Interfaces
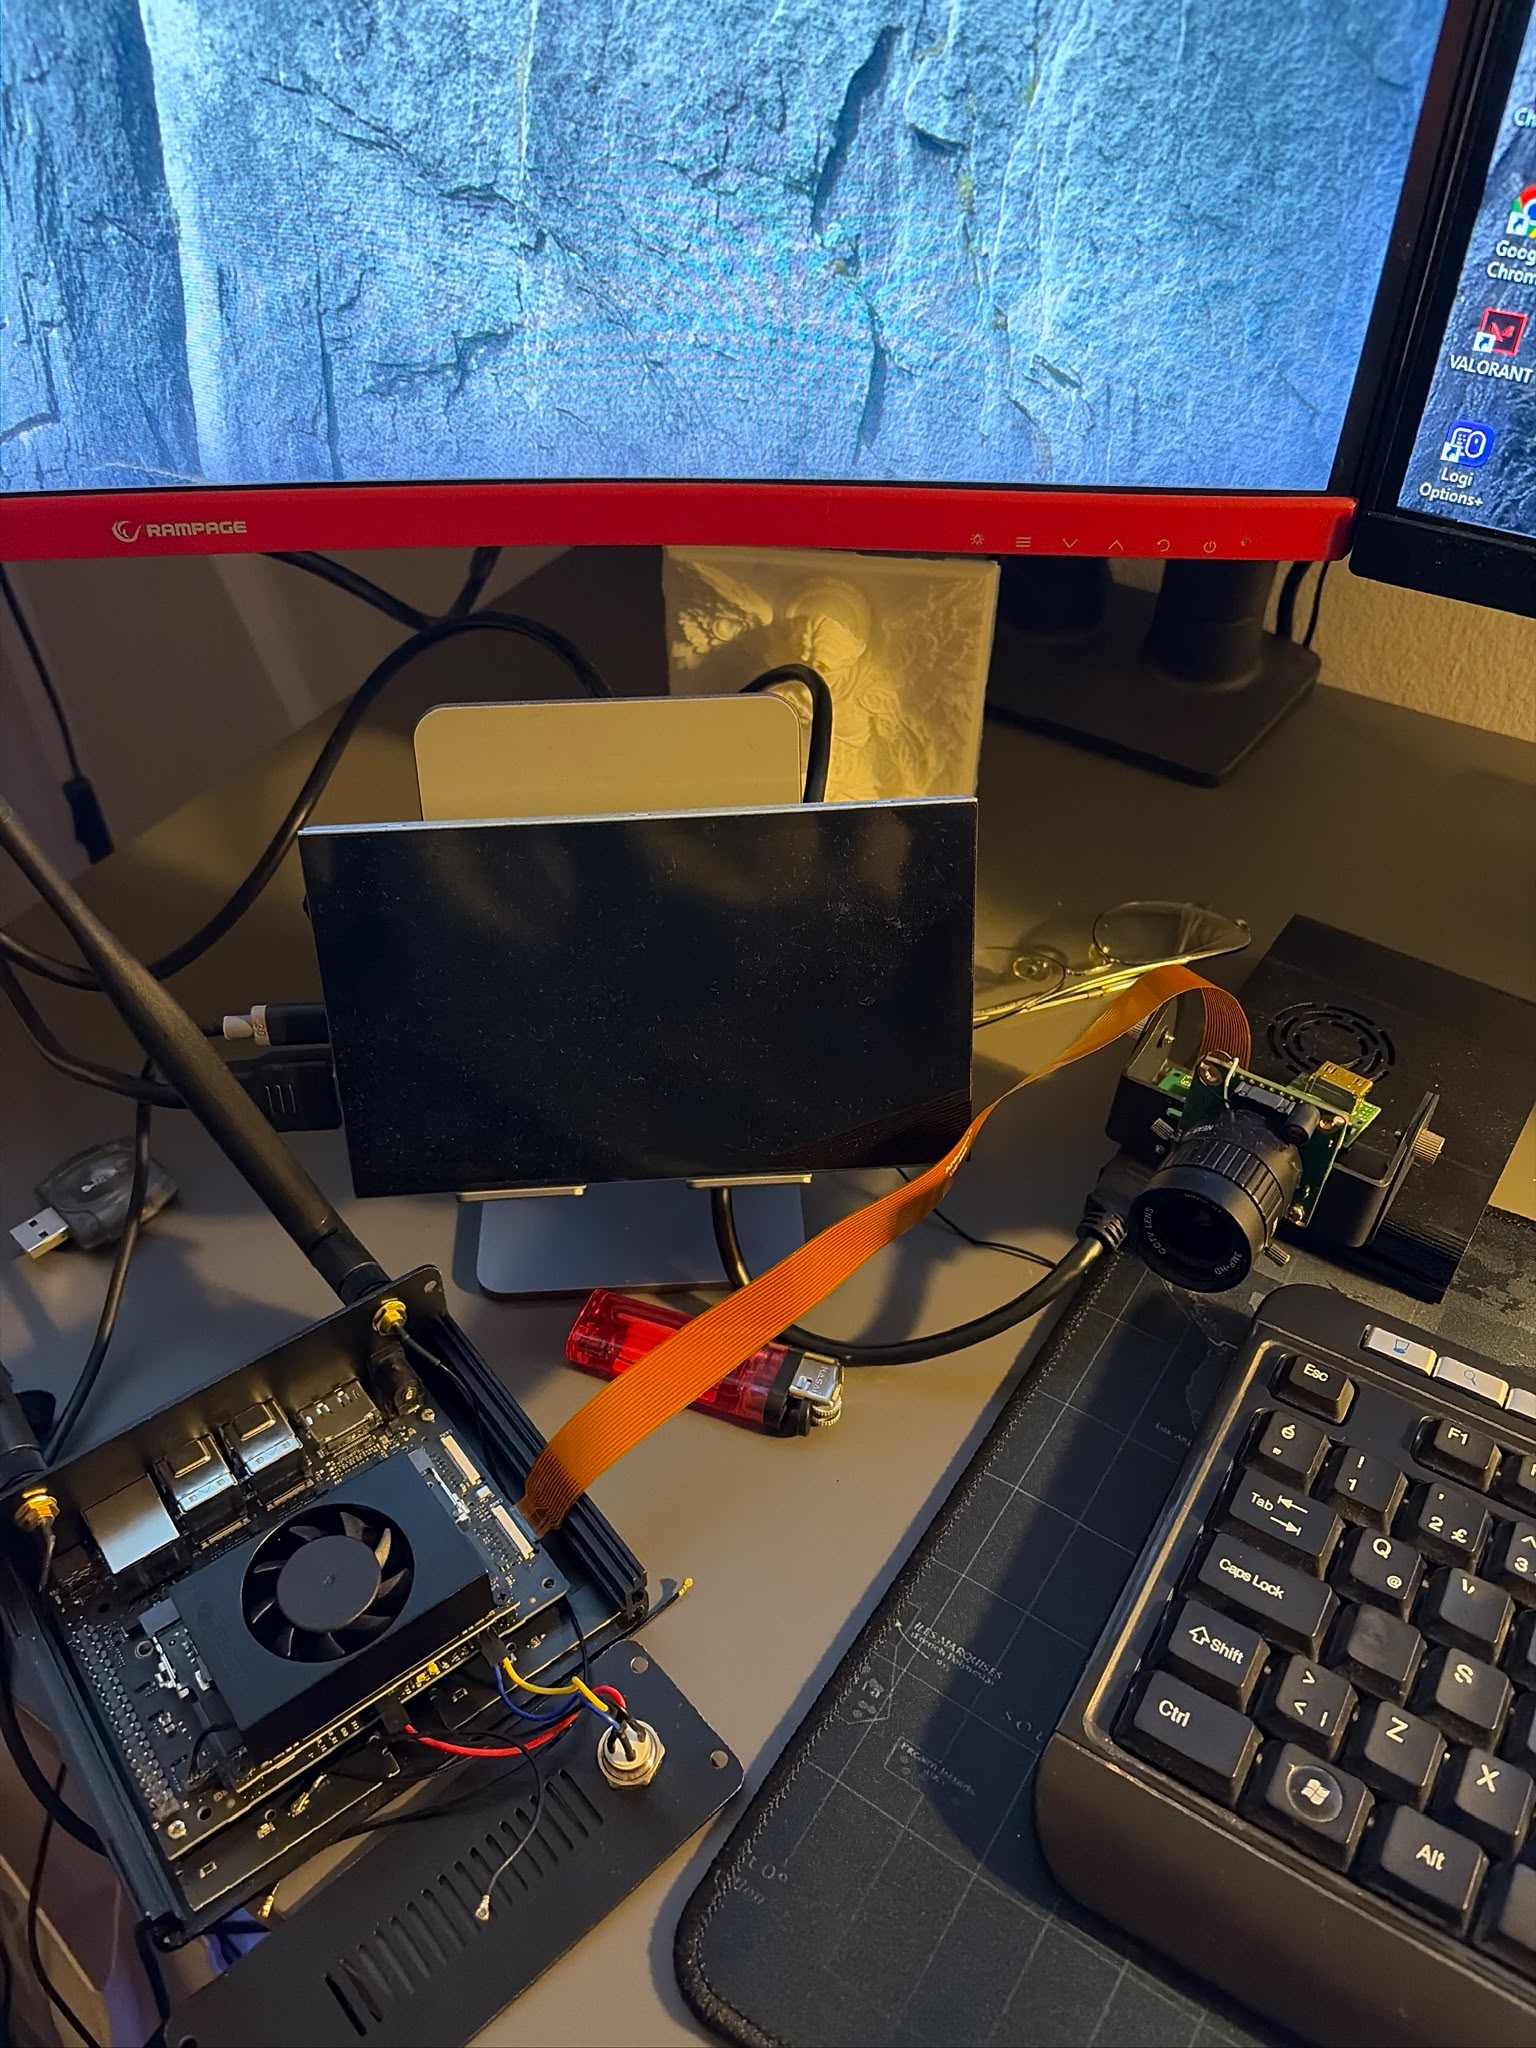
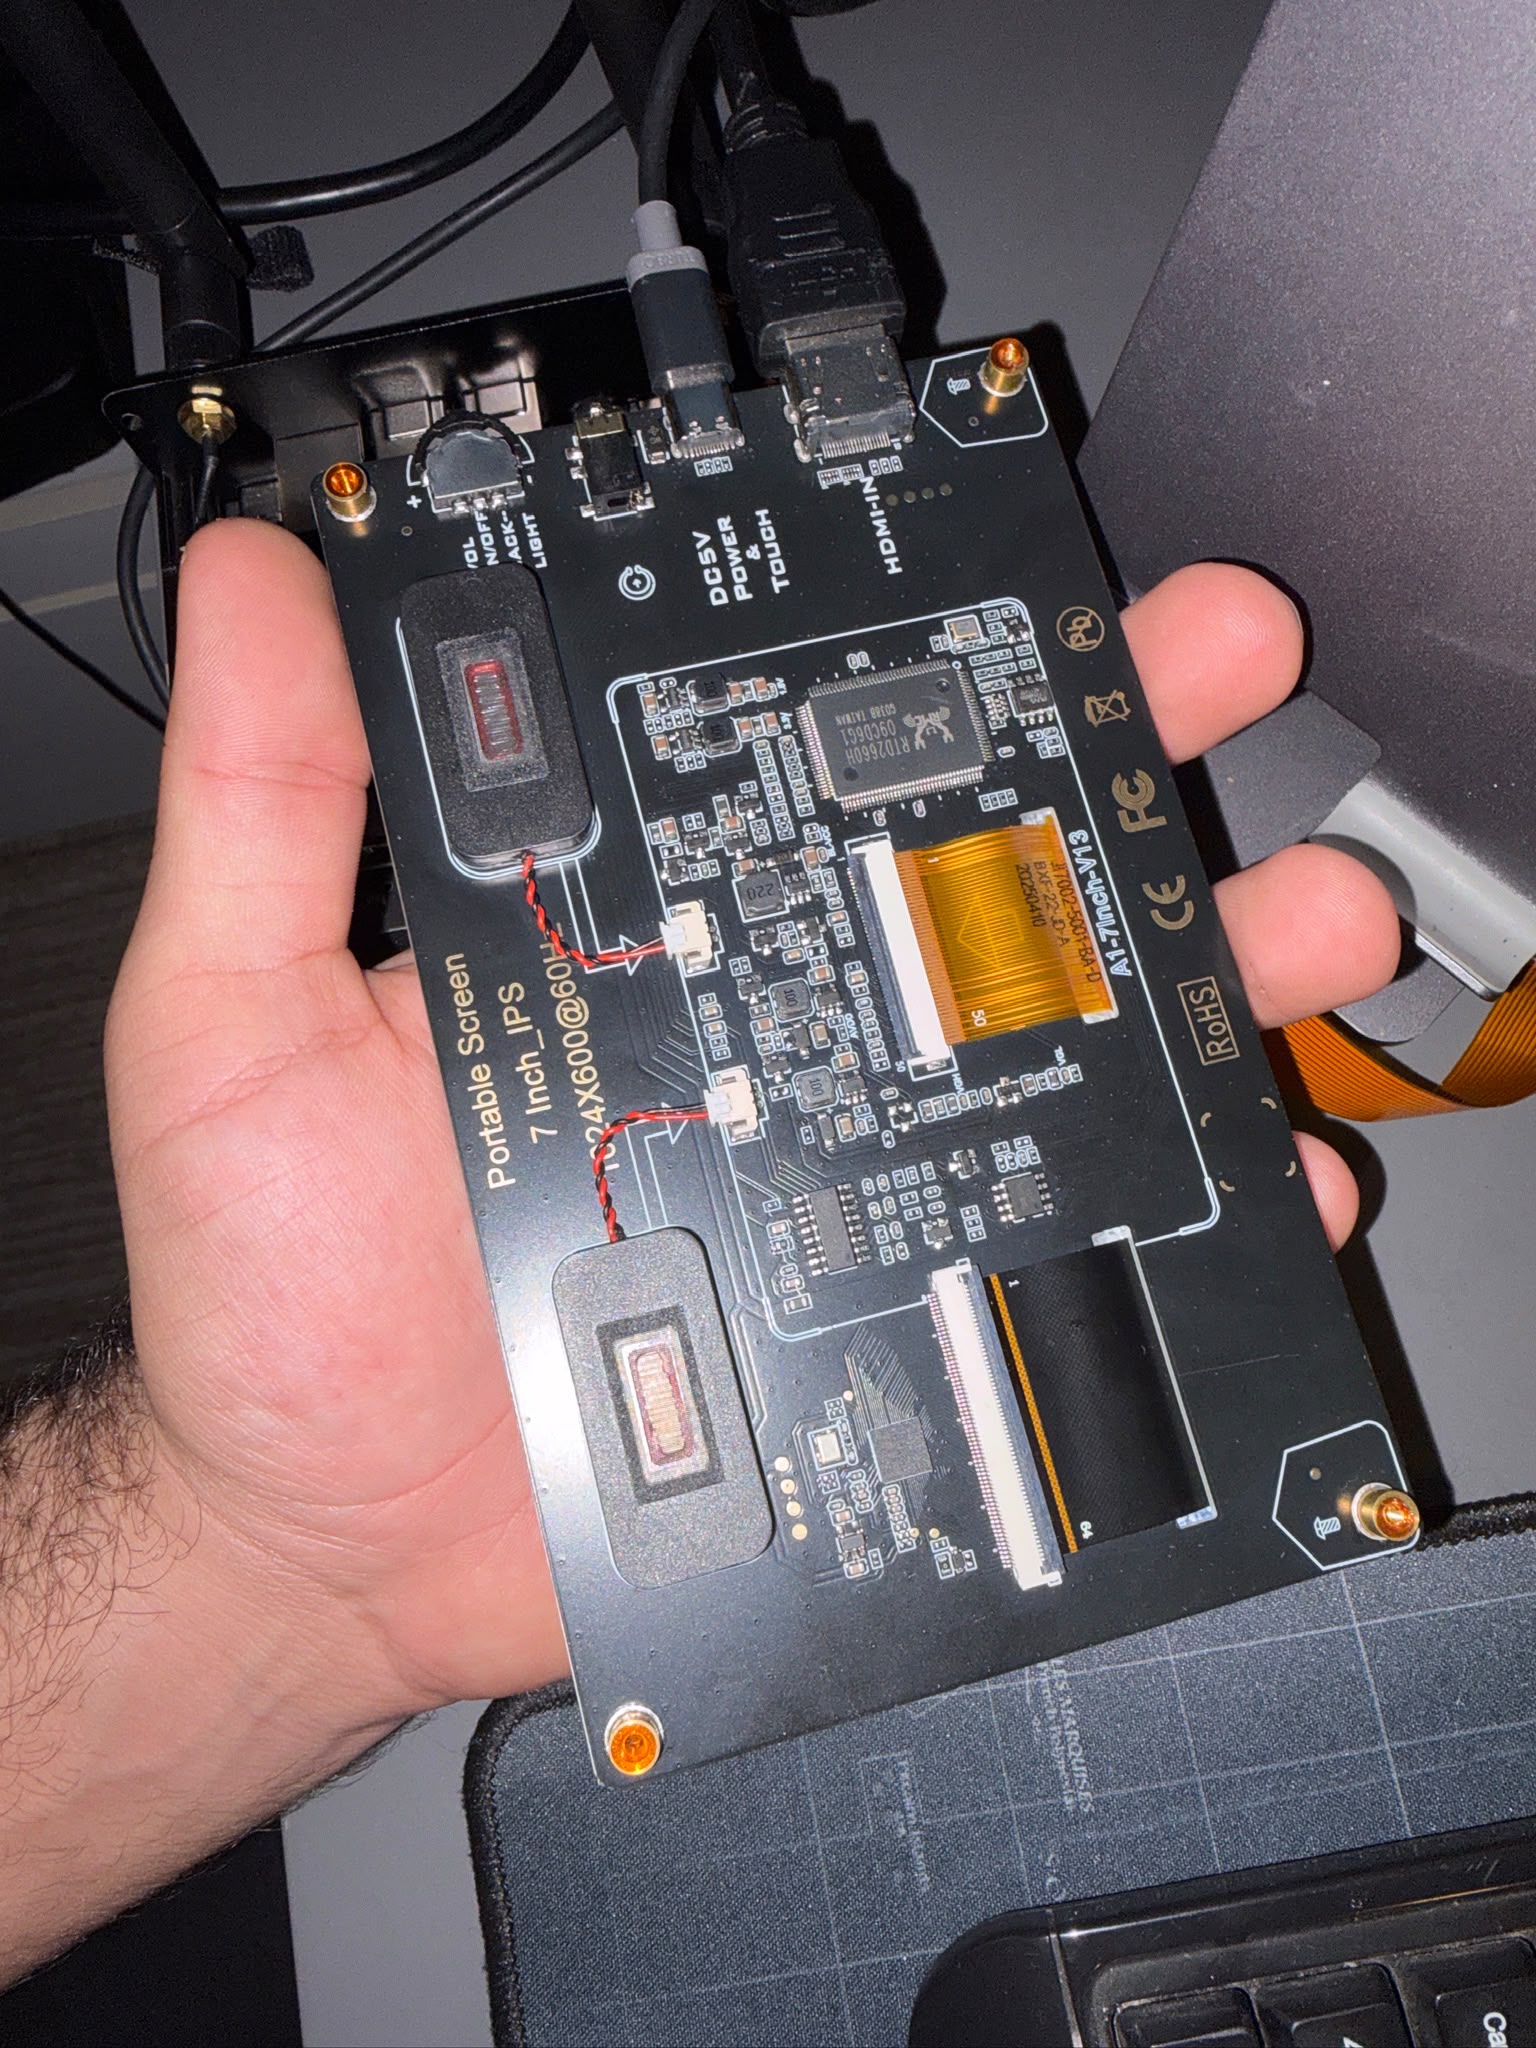
Embedded Systems bridge high-level AI compute nodes with deterministic real-time microcontrollers. MIPI CSI-2 camera lanes, I2C/UART/SPI sensor buses, display driver PCBs (RTD2660H), and RF transceivers are bench-verified in the REVEROB lab.
- Primary Compute Nodes
- Raspberry Pi 5, Raspberry Pi CM5, NVIDIA Jetson Orin Nano
- Microcontroller & RISC-V
- ESP32 (Wi-Fi/BLE), Sipeed Maixduino K210 (RISC-V KPU), Arduino Uno
- Camera & Display Buses
- MIPI CSI-2 (IMX477 / UC-392), HDMI/LVDS 7" 1024x600 IPS (RTD2660H)
- Hardware Protocols
- I2C, UART, SPI, PWM, GPIO, NRF24 2.4GHz RF Telemetry
// VERIFIED ENGINEERING CAPABILITIES
- Multi-tier compute architecture: Linux SBC mission control paired with MCU real-time actuation
- Low-latency hardware integration of Sony IMX477 and UC-392 MIPI CSI-2 camera rigs
- Portable ground control station prototyping with 7-inch 1024x600 IPS panels and RTD2660H driver PCBs
- Real-time polling of AMG8833 (I2C), TFmini-S (UART), and MQ-2 (ADC/GPIO) sensor arrays
ENGINEERING SOFTWARE
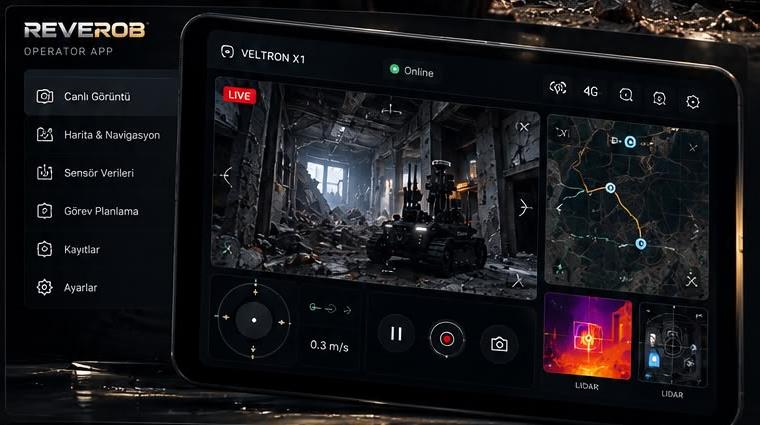
REVEROB OS (React + Electron), Robot Fleet Management, 2FA Security & OTA Update Center
REVEROB OS is a modular robotics management and control software ecosystem engineered to command field robot nodes from a unified console. Built around React and Electron alongside mobile/tablet field interfaces, it features 2FA operator security and an OTA Update Center.
- Command Interface Stack
- React + Electron Desktop Console & Cross-Platform Field App
- Security Architecture
- Two-Factor Authentication (2FA) & Role-Based Operator Access
- Deployment Infrastructure
- REVEROB Update Center — OTA (Over-The-Air) Package & Version Control
- Telemetry Monitoring
- Live Video, Thermal, Battery, Gas, LiDAR & Link Health Diagnostics
// VERIFIED ENGINEERING CAPABILITIES
- Centralized monitoring of multi-node robot status, battery diagnostics, and sensor streams
- 2FA operator authentication safeguarding critical actuation and mission commands
- OTA Update Center supporting staged software/firmware deployment and version rollback across nodes
- High-contrast "Metallic Night" industrial UI engineered for low-glare field operations
RESEARCH & DEVELOPMENT
Prototype Development, CAD-to-Print Additive Manufacturing, Micro-Turbine Propulsion & Validation
REVEROB R&D enforces a systematic 7-stage engineering methodology—progressing from manual drafting blueprints and 3D CAD assemblies to additive manufacturing fabrication and live micro-turbojet ignition testing.
- Design & Modeling
- Manual Technical Drafting + 3D Parametric CAD + Blender Visualization
- Additive Manufacturing
- Bambu Lab / Creality Ender-3 V3 KE CAD-to-Print Prototyping
- Propulsion & Mechatronics
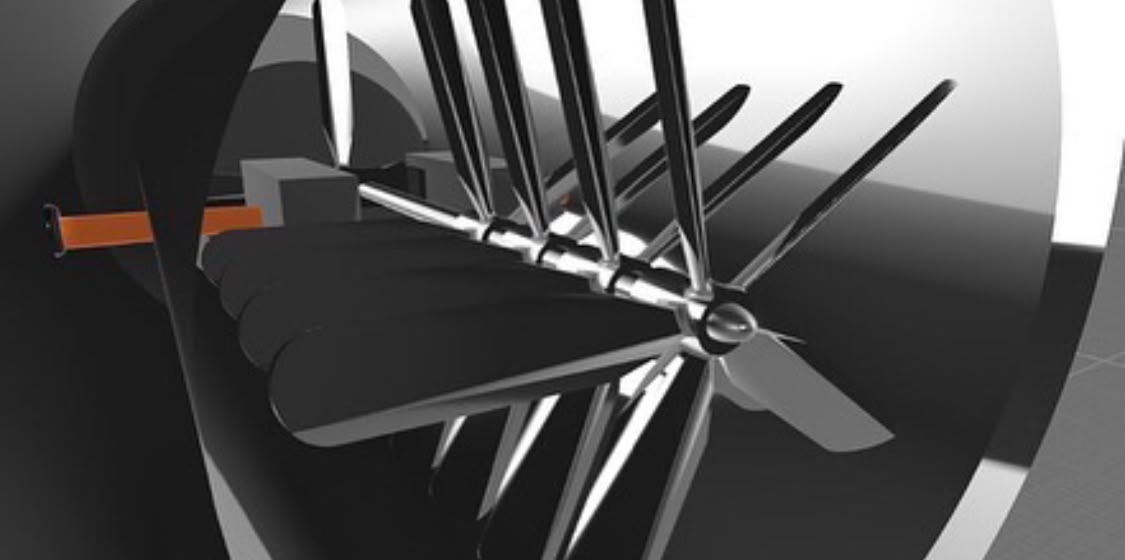
- Axial Micro-Turbine Rotor CAD, Live Ignition Rig & Smart Elevator Tower
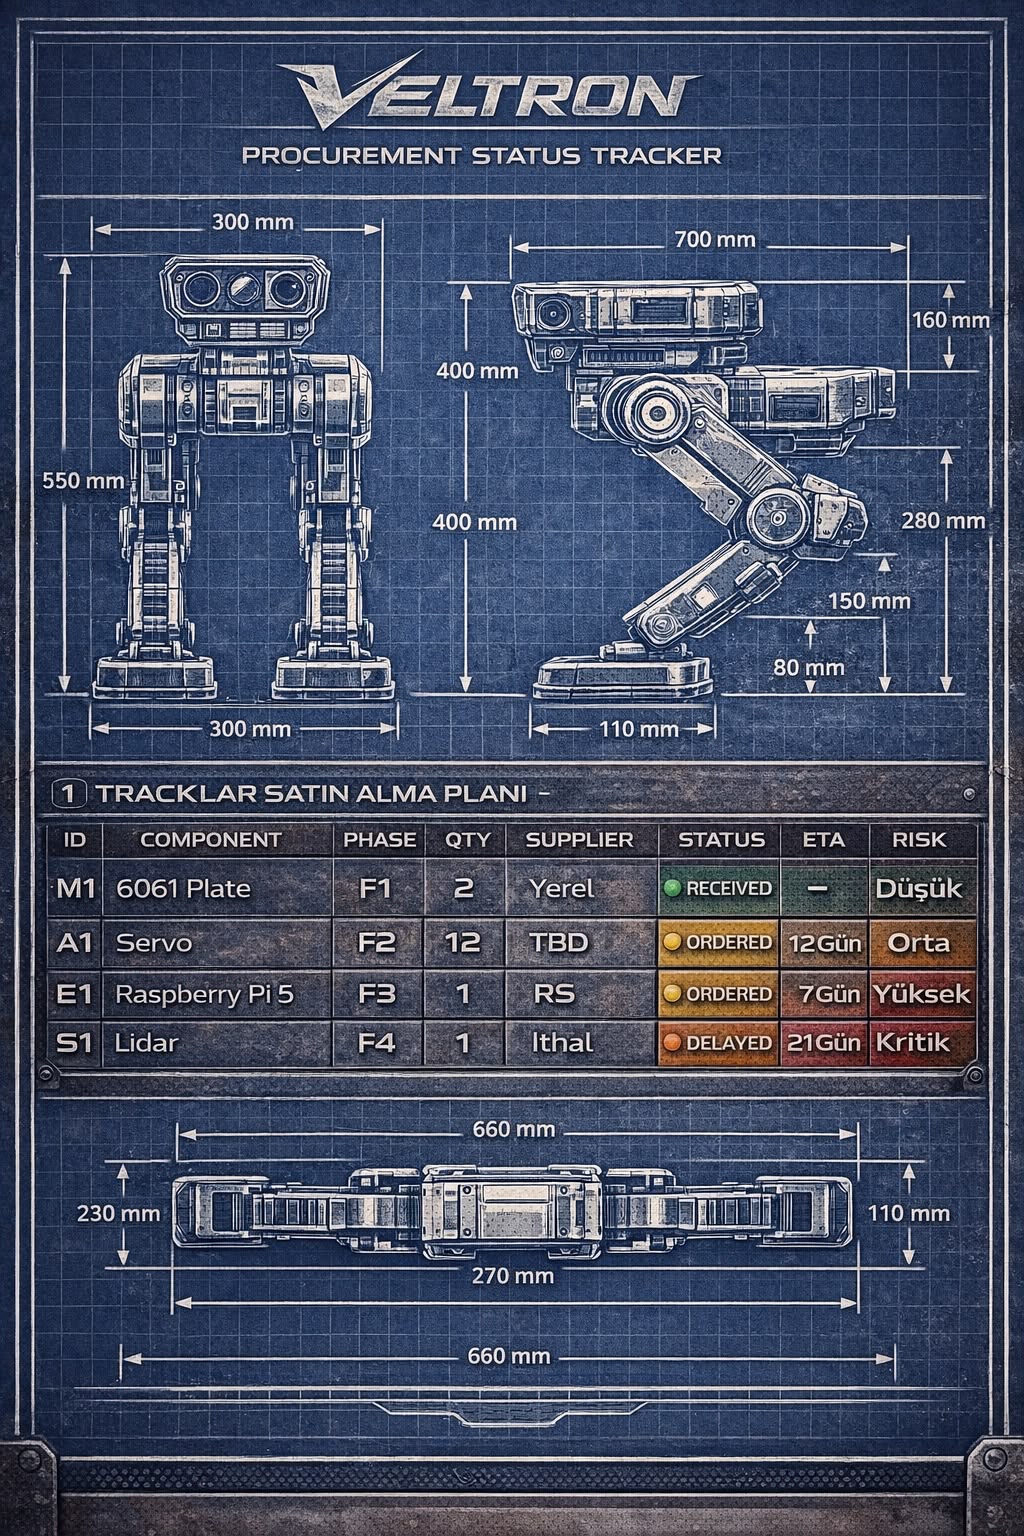
- Procurement & BOM Tracking
- Structured Subsystem BOM, Procurement & Integration Tracking Matrix
// VERIFIED ENGINEERING CAPABILITIES
- Custom ergonomic handheld controller enclosure CAD modeling and 3D-printed assembly
- Micro-jet engine internal cutaway analysis, rotor shaft assembly, and live flame ignition validation
- Technical blueprint documentation and hardware procurement tracking for VELTRON subsystems
- Continuous mechanical and electronic revision cycles driven by bench test telemetry