REVEROB OS & UPDATE CENTER
The central modular robotics management, AI computer vision, telemetry, and cyber-secure command platform of the REVEROB ecosystem—delivering end-to-end control from desktop workstations and field tablets down to embedded robot nodes.
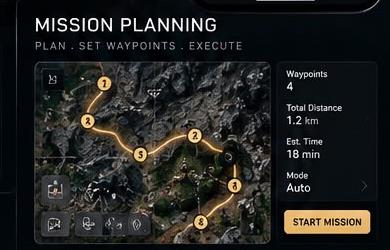 MISSION PLANNING
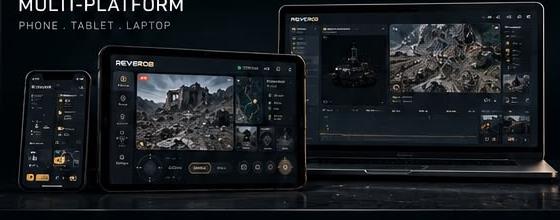 MULTI-DEVICE
FOUR-TIER DISTRIBUTED CONTROL & FAIL-SAFE ARCHITECTURE
REVEROB OS decouples high-level AI inference from real-time motion control and hardware safety loops (fail-safe), ensuring mission-critical reliability.
NVIDIA Jetson Orin Nano — Central Control Layer
Positioned as the high-level compute node, NVIDIA Jetson Orin Nano executes GPU/Tensor-intensive workloads including YOLOv8 object detection, multi-target Kalman Filter tracking, optical-thermal image fusion, and mission decision logic.
- • YOLOv8 TensorRT gerçek zamanlı çıkarım (inference)
- • Kalman Filtresi durum tahmini ve hedef yörünge takibi
- • Yüksek bant genişlikli kamera (IMX477) ön işleme
- • REVEROB OS istemcisi ile şifreli telemetri/video yayını
Heavy GPU load or process latency in the AI layer never directly drives motor hardware; the Jetson transmits validated velocity/heading vectors to the Raspberry Pi 5 control node.
REVEROB OS SOFTWARE MODULES
Operator Command Dashboard
Unified Telemetry, Camera Stream & System Status Interface
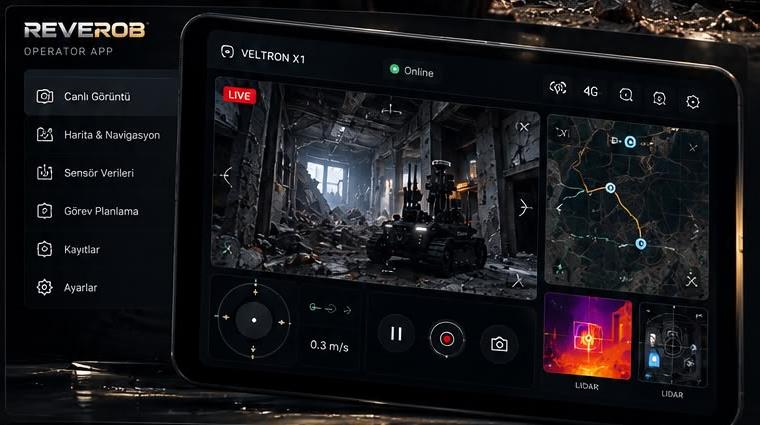
Built with React and Electron for desktop and field tablet operation, the dashboard consolidates live camera feeds, battery voltage, compute load, active mission state, and emergency stop (E-Stop) controls into a single low-latency screen.
- Multi-pane layout: Camera HUD + Telemetry + Command Console
- Low-latency WebSocket / WebRTC data and video streaming
- Compatible with desktop workstation, field tablet, and handheld GCS
- Real-time system alerts and link-integrity indicator
The REVEROB Update Center console below is an interactive engineering preview of the planned OTA update architecture designed for Jetson Orin Nano, Raspberry Pi 5, and embedded nodes.
SECURE A/B UPDATES, SHA-256 VERIFICATION & ROLLBACK ARCHITECTURE
NVIDIA Jetson Orin Nano // AI Vision & TensorRT Bundle
REVEROB UPDATE CENTER — 15 TARGET CAPABILITIES MATRIX (PLANNED INFRASTRUCTURE)
Wireless delivery of encrypted update bundles to field robots without physical tethering.
Centralized dispatch of system services, containers, and configuration profiles to target nodes.
Updating YOLOv8 model weights, TensorRT engines, and high-level autonomy services.
Updating low-level motion control, sensor polling daemons, and hardware bridge services.
Safe serial-bus firmware flashing for ESP32, Arduino, and auxiliary sensor/motor boards.
Asymmetric cryptographic signature verification preventing unauthorized code execution.
Bit-level SHA-256 integrity verification of every downloaded image and binary prior to staging.
Semantic versioning (SemVer) tree and version pinning across all hardware and software layers.
Pre-install validation of hardware revision, OS kernel, and sensor driver dependency matrices.
Chunked resumable transfers ensuring reliable package delivery over intermittent field links.
Immutable timeline recording package versions, timestamps, and authorizing operator signatures.
Automated boot-up verification of telemetry, camera pipelines, and safety loops on first run.
Instant fallback to the last known-good version if post-boot health checks fail.
Staging updates to an inactive partition (Slot B) while Slot A runs, swapping atomically on reboot.
Validating new releases on a designated test unit before staged rollout across the fleet.
REVEROB OS, COMMAND HARDWARE & DEVELOPMENT ARCHIVE
Authentic REVEROB archive visuals showing desktop command screens, field tablet UIs, IDE development sessions, embedded TFT assistant unit, and handheld controller.
REVEROB Operator Command Interface
Primary operator screen integrating live camera feeds, system telemetry, and control panels.
Mission Planning & Navigation UI
Module interface for configuring waypoints, field maps, and mission execution parameters.
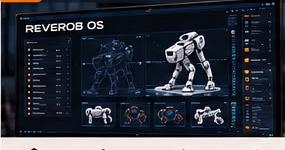
REVEROB OS Desktop System View
Dark-mode engineering interface built on the React and Electron architecture.
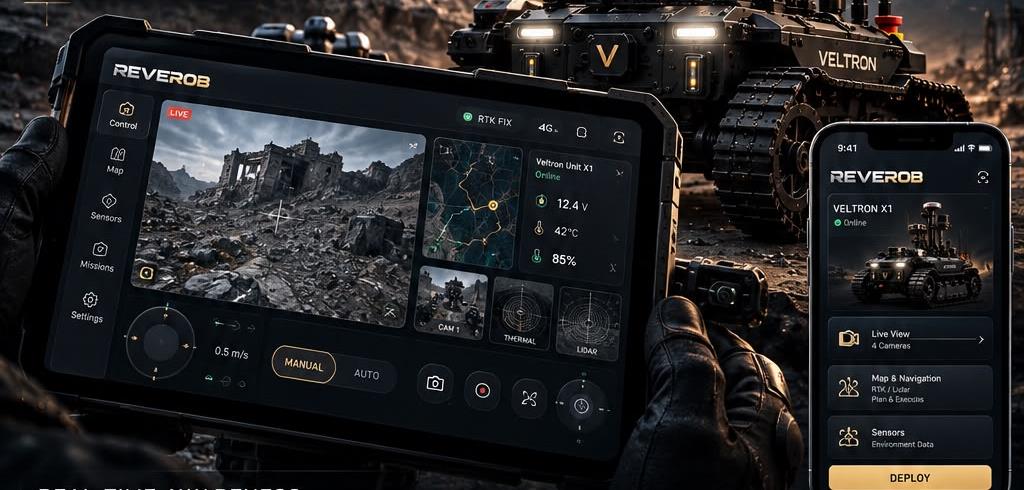
Field Tablet & Mobile Operations UI
Touch-optimized layout for field operations and real-time telemetry monitoring.
Multi-Platform Ecosystem Architecture
REVEROB OS running across desktop workstation, laptop, tablet, and mobile form factors.
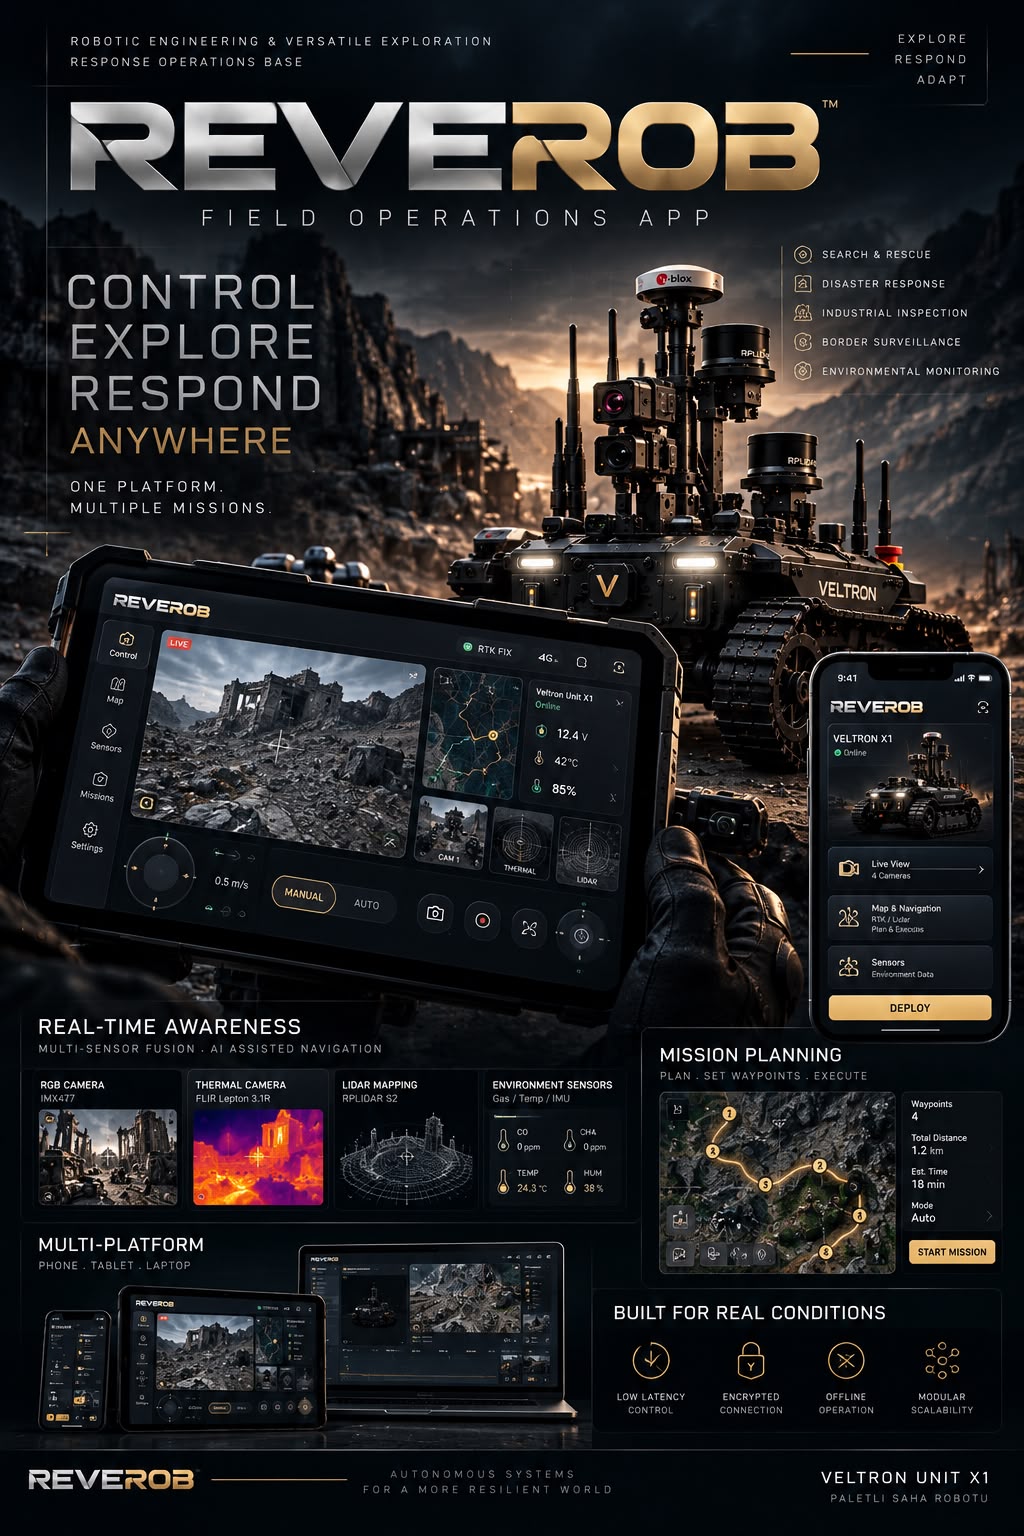
REVEROB Field Operations Application Poster
Original project visual highlighting remote monitoring, alerting, and field control capabilities.
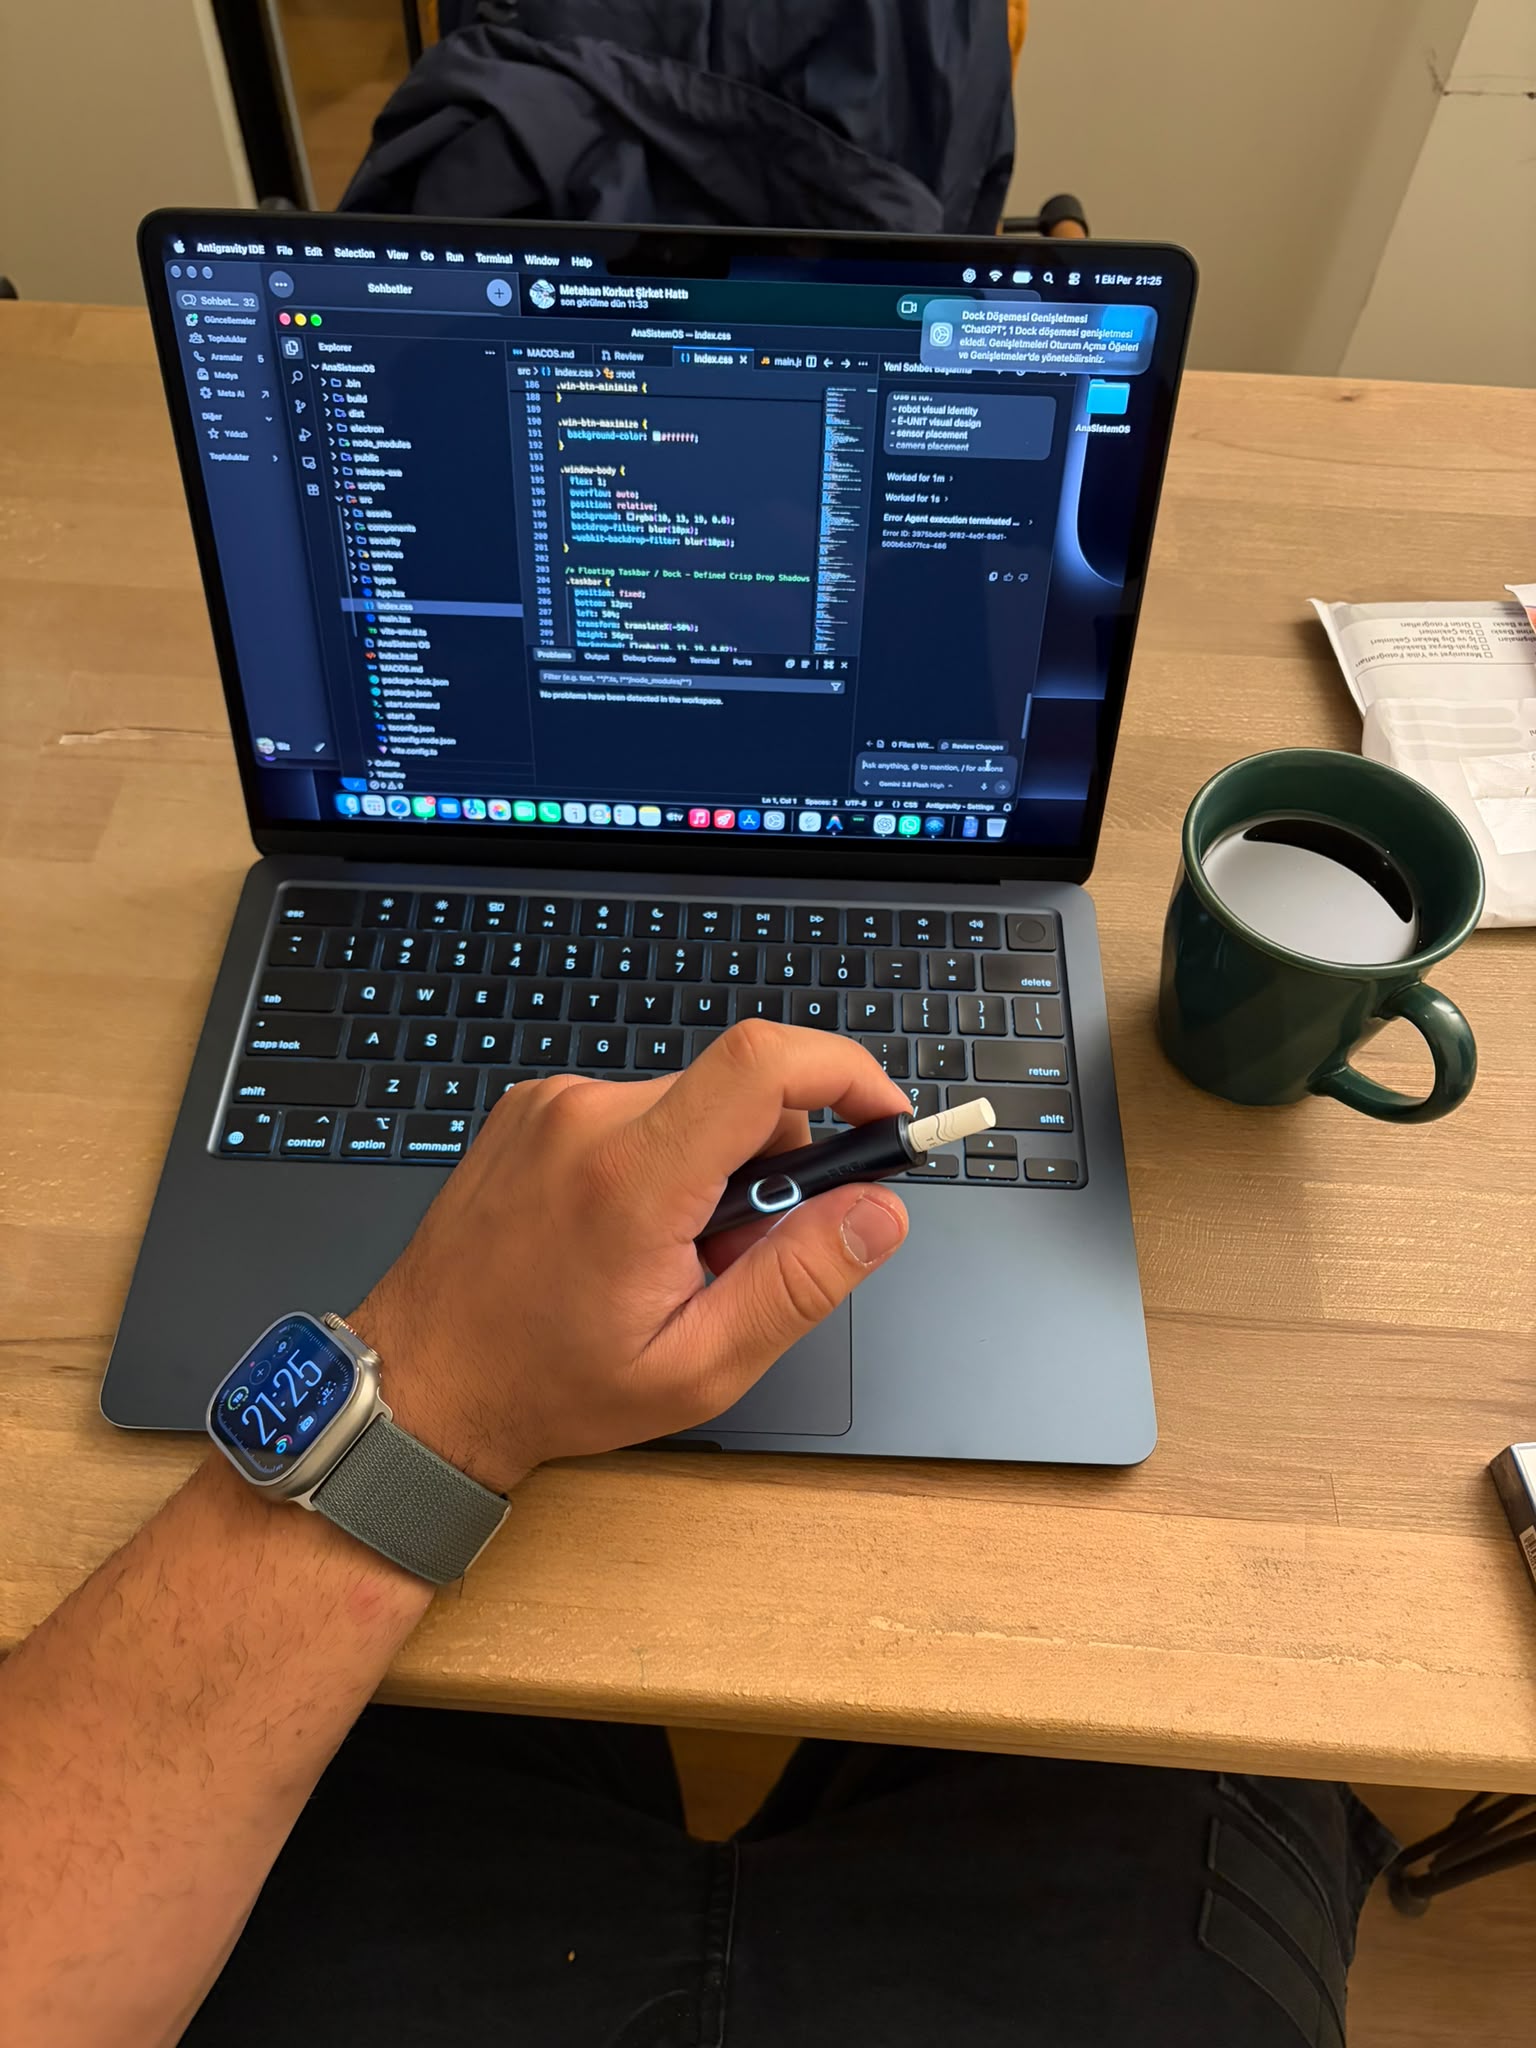
REVEROB OS Software Development Environment (IDE)
In-lab software engineering session showing REVEROB OS source code and system services development.
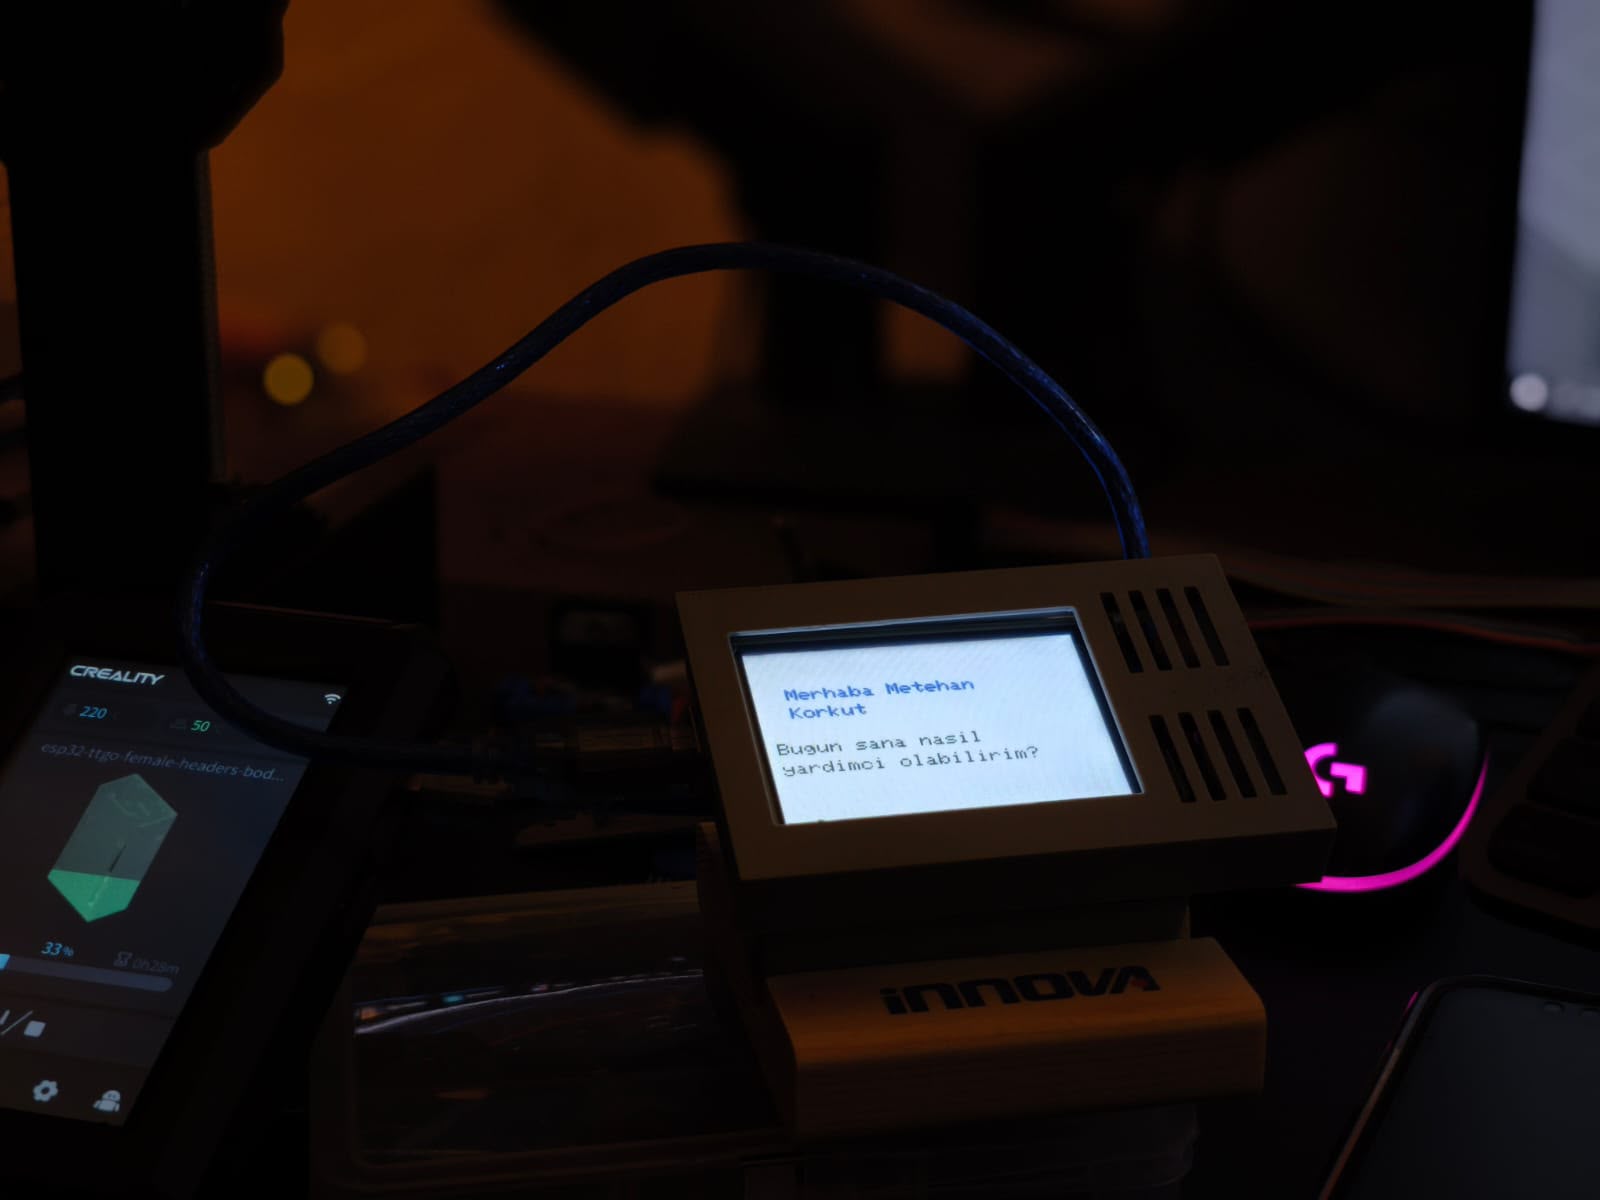
Embedded Smart Assistant & TFT Status Unit
TFT-equipped embedded unit developed for user interaction and desktop status notifications within the REVEROB ecosystem.
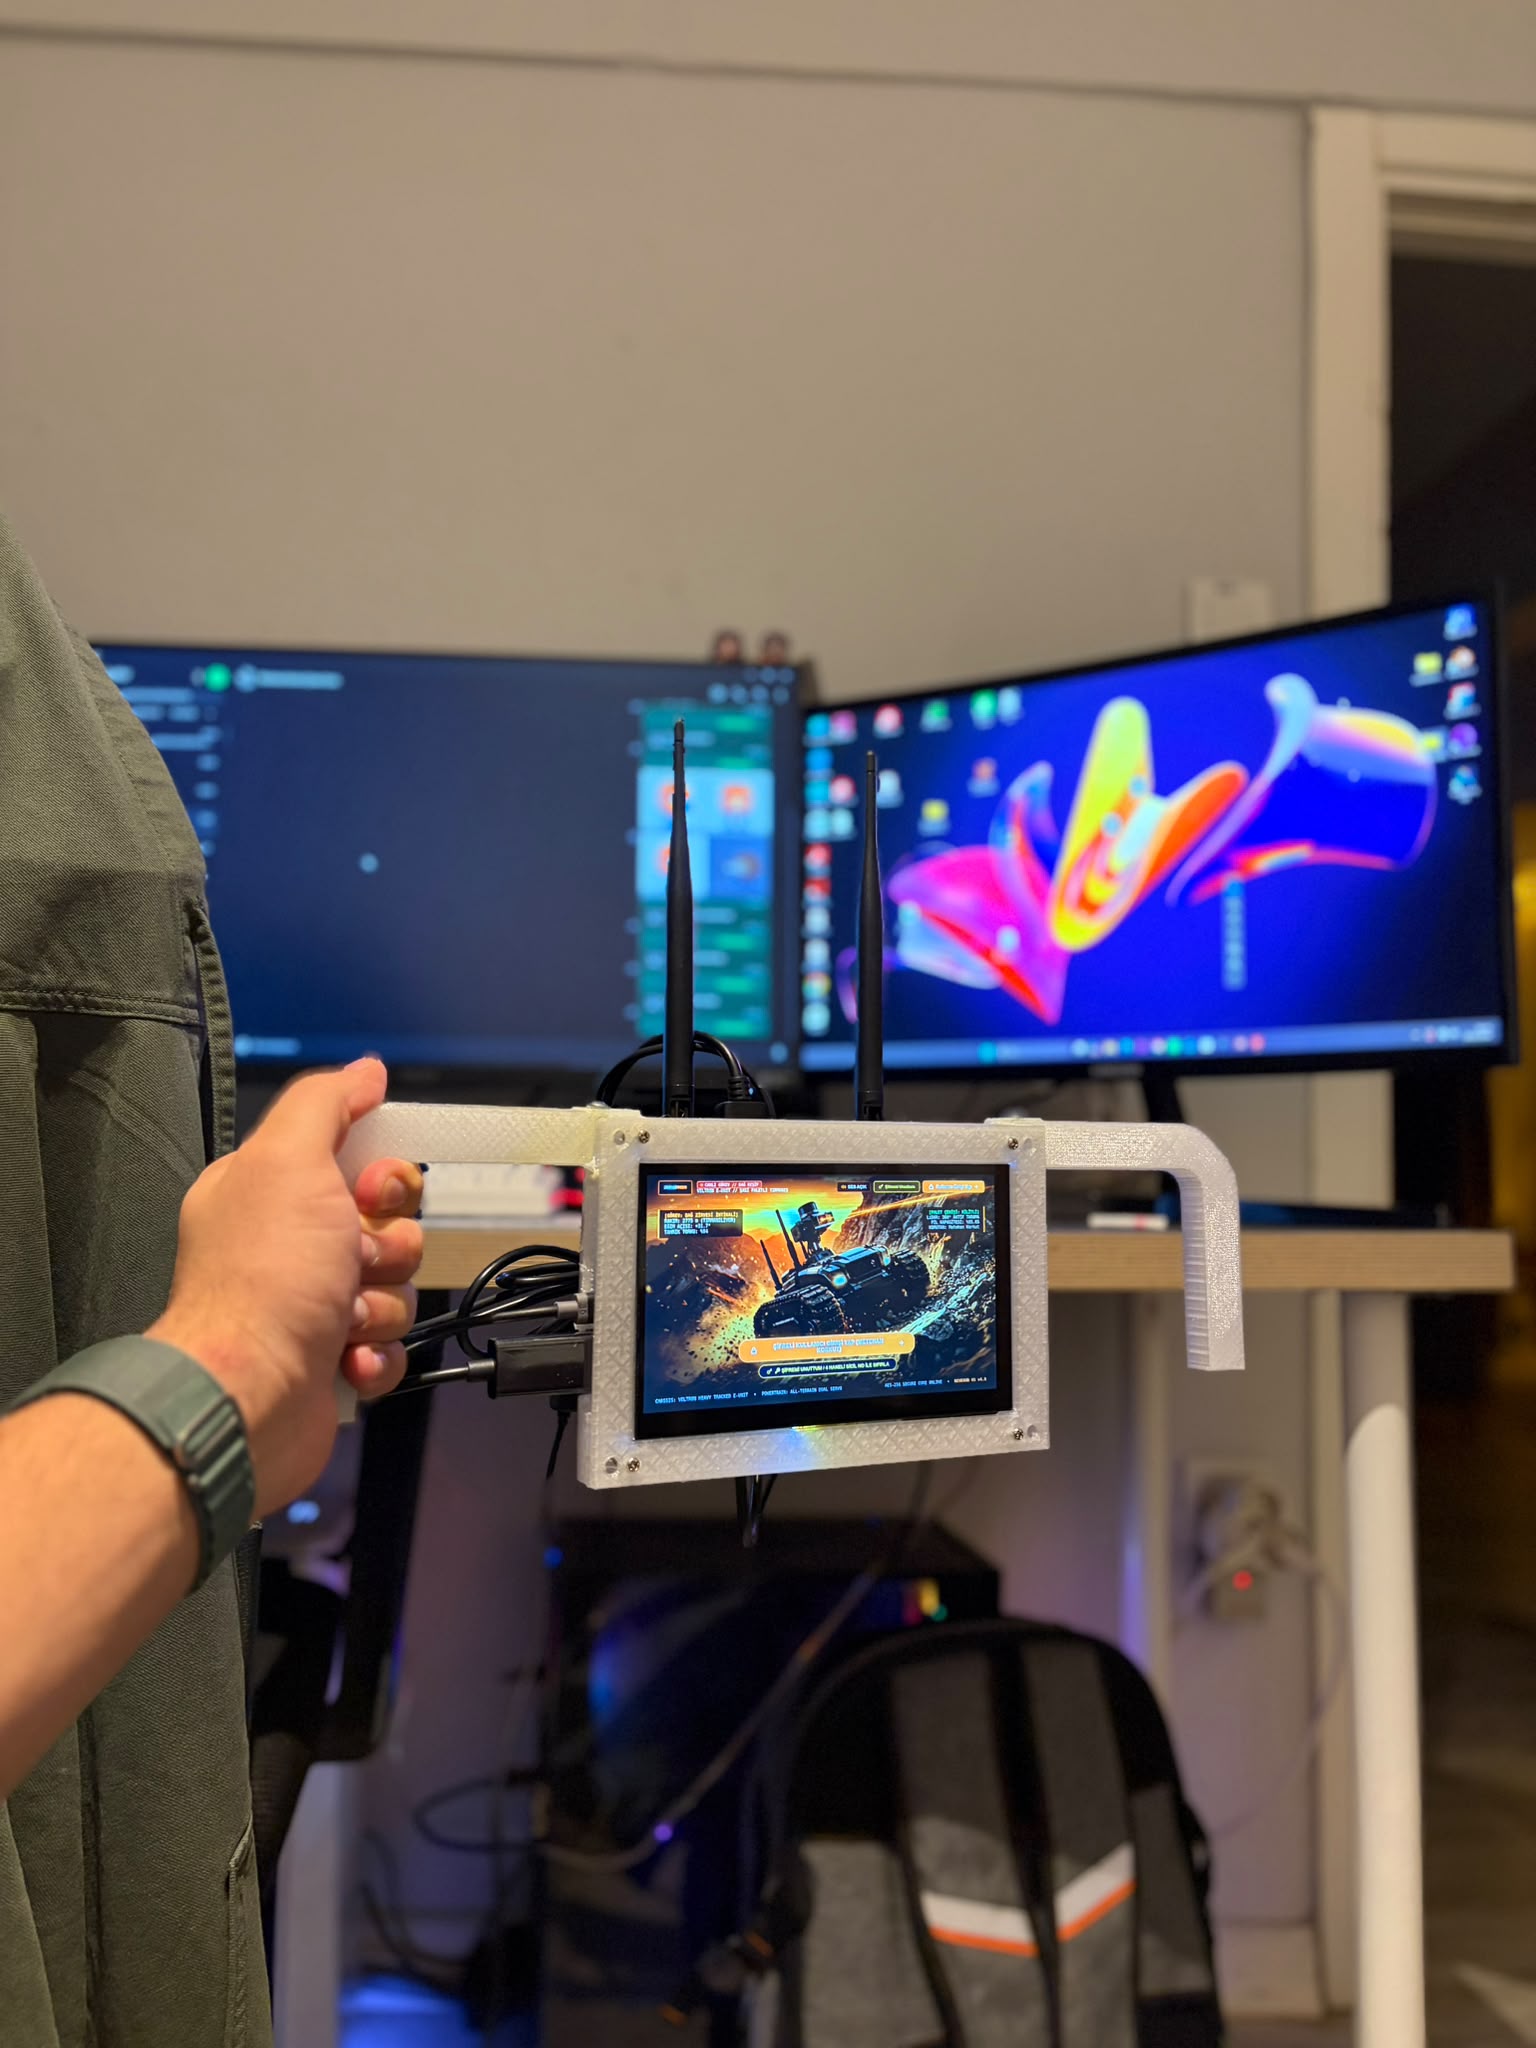
Portable Handheld Ground Control Station (GCS)
Hardware prototype featuring integrated display, dual analog joysticks, and tactical switches for REVEROB OS field teleoperation.