VELTRON UNIT X1
MODULAR TRACKED & MULTI-SENSOR ROBOTIC PLATFORM
VELTRON UNIT X1 is REVEROB’s flagship tracked robotics development project engineered around intelligent perception, multi-sensor integration (optical, thermal, LiDAR, gas), and autonomous robotics research.
360° MODEL ROTATION, SENSOR HOTSPOTS & ASSEMBLY ANALYSIS
/assets/veltron/veltron-unit-x1-concept.gltfOPT-01 — Sony IMX477 CSI Camera Module
High-Resolution Optical Imaging Sensor (CSI-2)
Real-time visual perception, YOLOv8 object detection, target tracking, and live operator video streaming.
Streams low-latency raw video frames over MIPI CSI-2 ribbon bus into the Raspberry Pi 5 and target Jetson Orin Nano computer vision pipeline.
Mounted in the primary optical bay of the VELTRON UNIT X1 upper sensor mast; serves as the primary feed for Kalman Filter object tracking.
THREE-LAYER ROBOTIC ARCHITECTURE: PERCEPTION, DECISION & ACTUATION
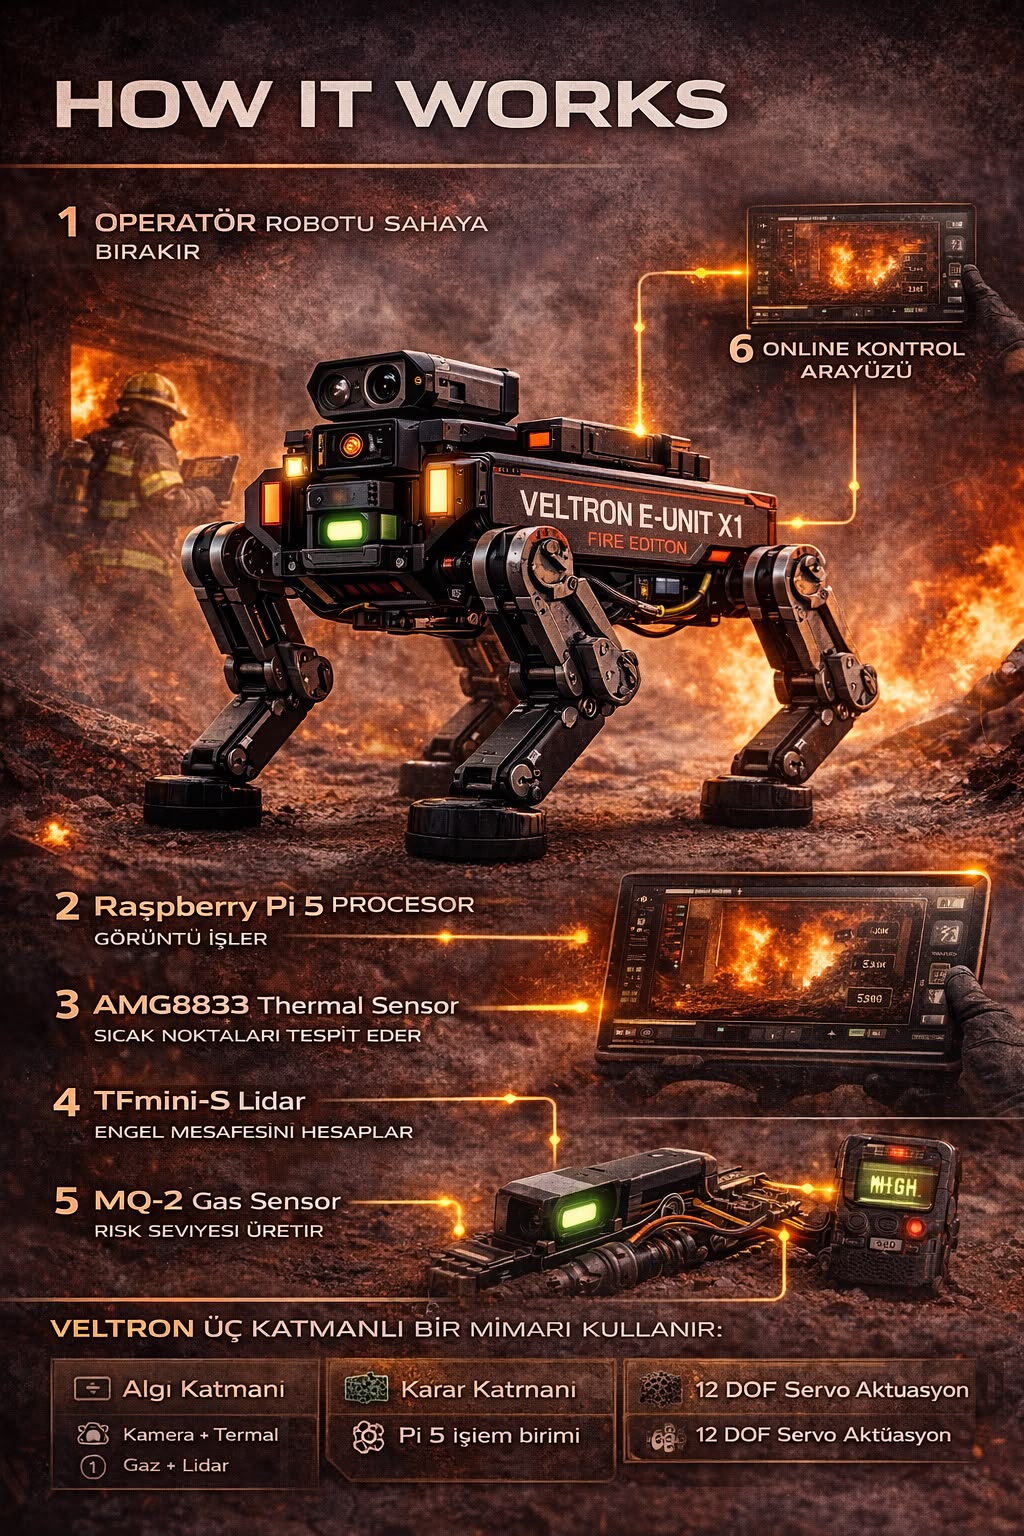
The VELTRON architecture (across both the tracked UNIT X1 field platform and the 12-DOF quadruped E-UNIT X1 research variant) separates sensor perception, embedded decision-making, and mechanical actuation into modular layers.
IMX477 CSI Camera (optical vision) + AMG8833 Thermal Sensor (hotspot detection) + TFmini-S LiDAR (obstacle distance) + MQ-2 Gas Sensor (hazard level generation).
Raspberry Pi 5 primary compute fuses sensor telemetry and runs local control; NVIDIA Jetson Orin Nano target architecture executes YOLOv8 detection, Kalman tracking, and REVEROB OS coordination.
High-traction tracked drive assembly on a 6061 aluminum chassis (UNIT X1) alongside parallel 12-DOF servo-actuated quadruped locomotion research (E-UNIT X1).
VERIFIED DEVELOPMENT OBJECTIVES
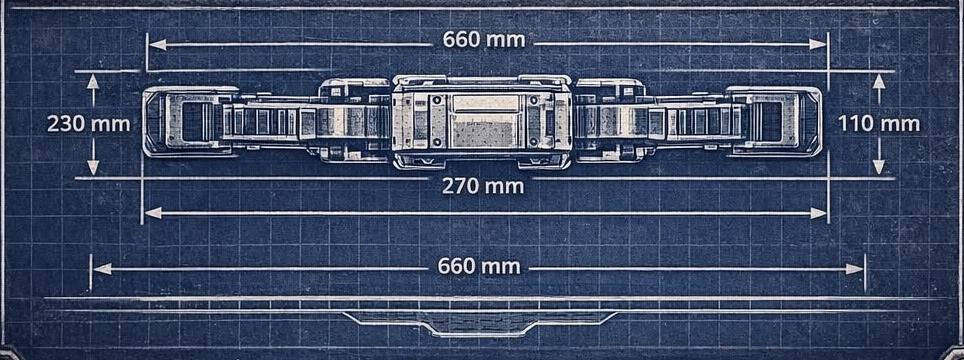
VERIFIED ENGINEERING DRAWINGS & COMPONENT PROCUREMENT TRACKER
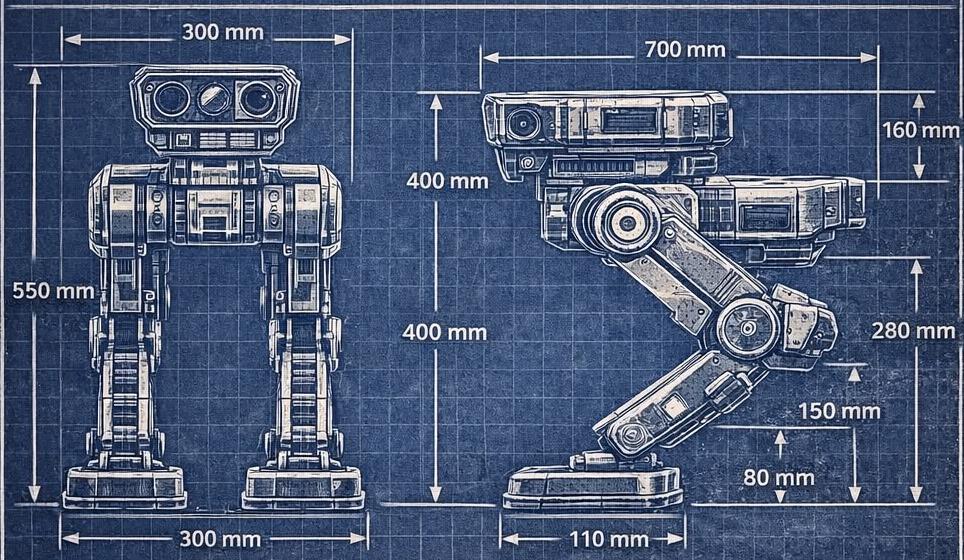
The technical blueprint and procurement status tracker below (Archive Asset #32) transparently document the orthographic reference dimensions and component procurement stages in the VELTRON R&D program.
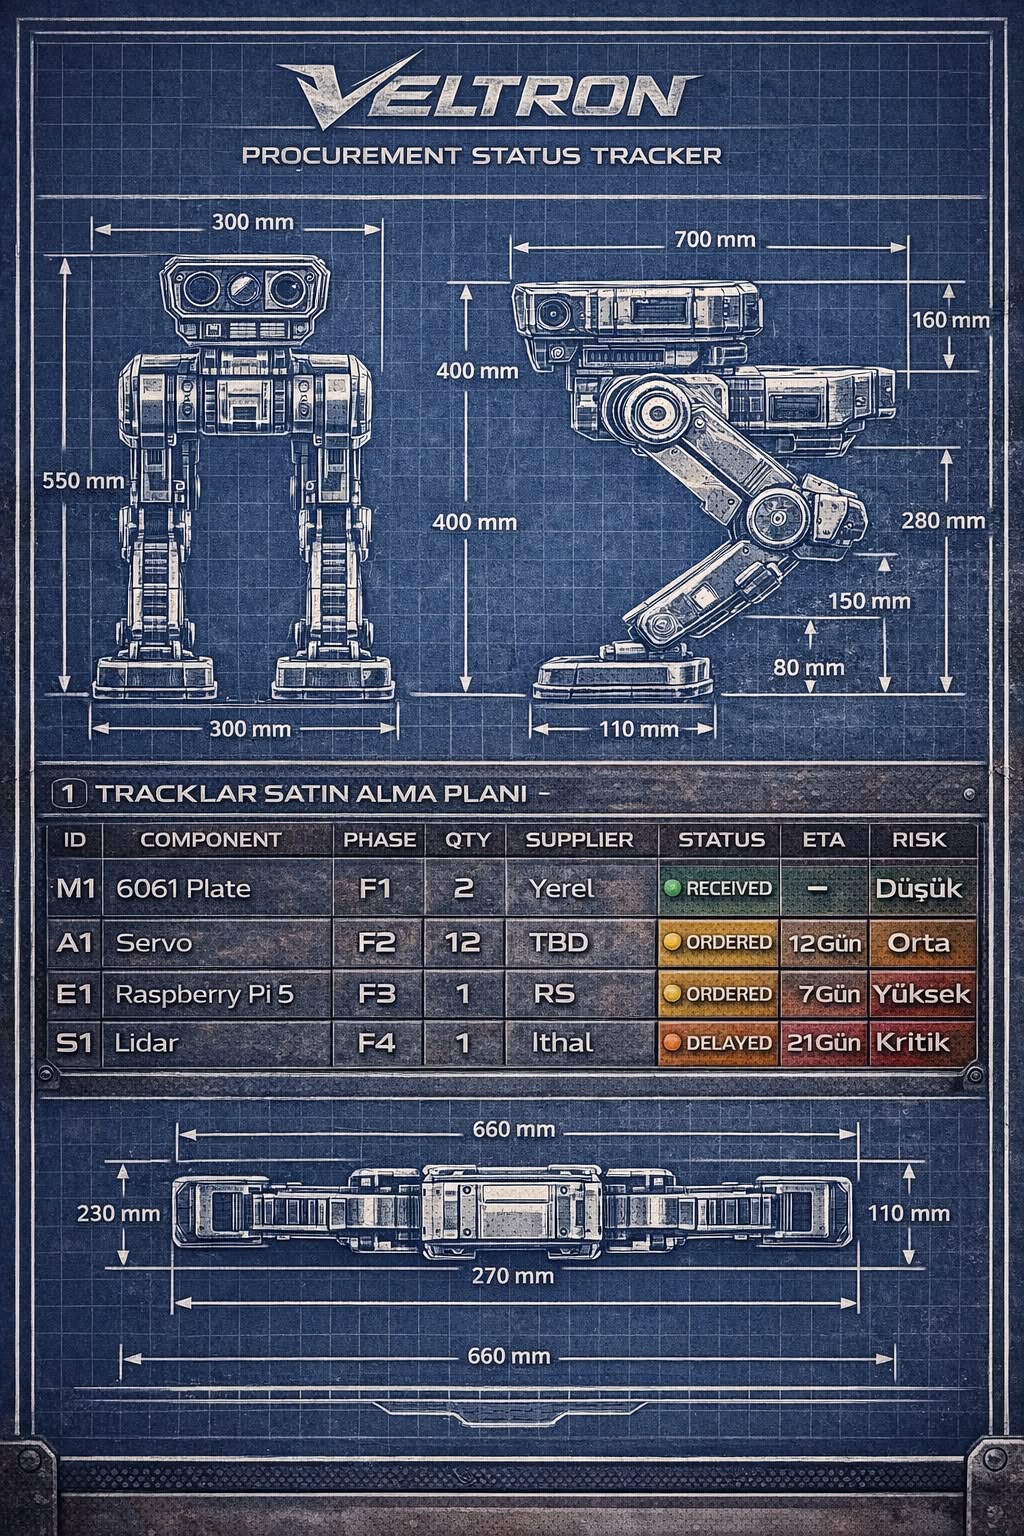
| ID | COMPONENT | PHASE | QTY | SUPPLIER | STATUS | ETA |
|---|---|---|---|---|---|---|
| M1 | 6061 Plate (Aluminum Chassis) | F1 | 2 | Local | RECEIVED | — |
| A1 | Servo Actuators (12-DOF Variant) | F2 | 12 | TBD | ORDERED | 12 Days |
| E1 | Raspberry Pi 5 (Main Compute) | F3 | 1 | RS | ORDERED | 7 Days |
| S1 | LiDAR Sensor Module | F4 | 1 | Import | IN PROCUREMENT | 21 Days |
VELTRON UNIT X1 is in active R&D and prototype development. In accordance with our strict engineering accuracy policy, unverified maximum speed, battery capacity, operating runtime, payload rating, or IP ingress ratings are not fabricated.
ORIGINAL RENDERS, FIELD POSTERS & HARDWARE PROTOTYPES
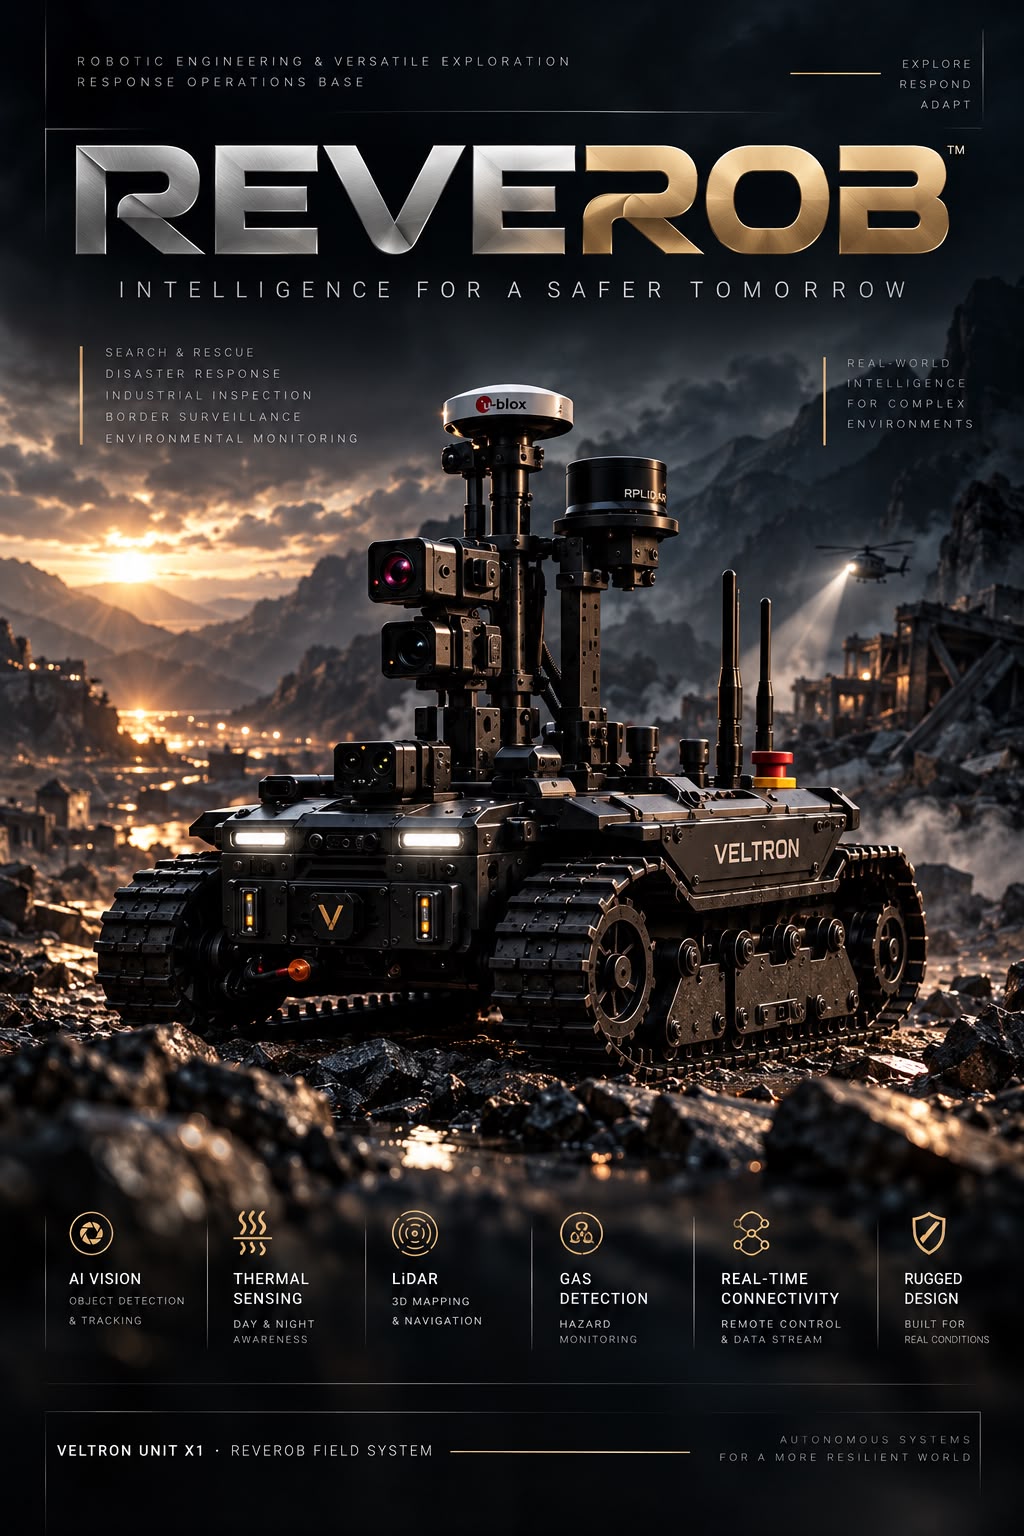
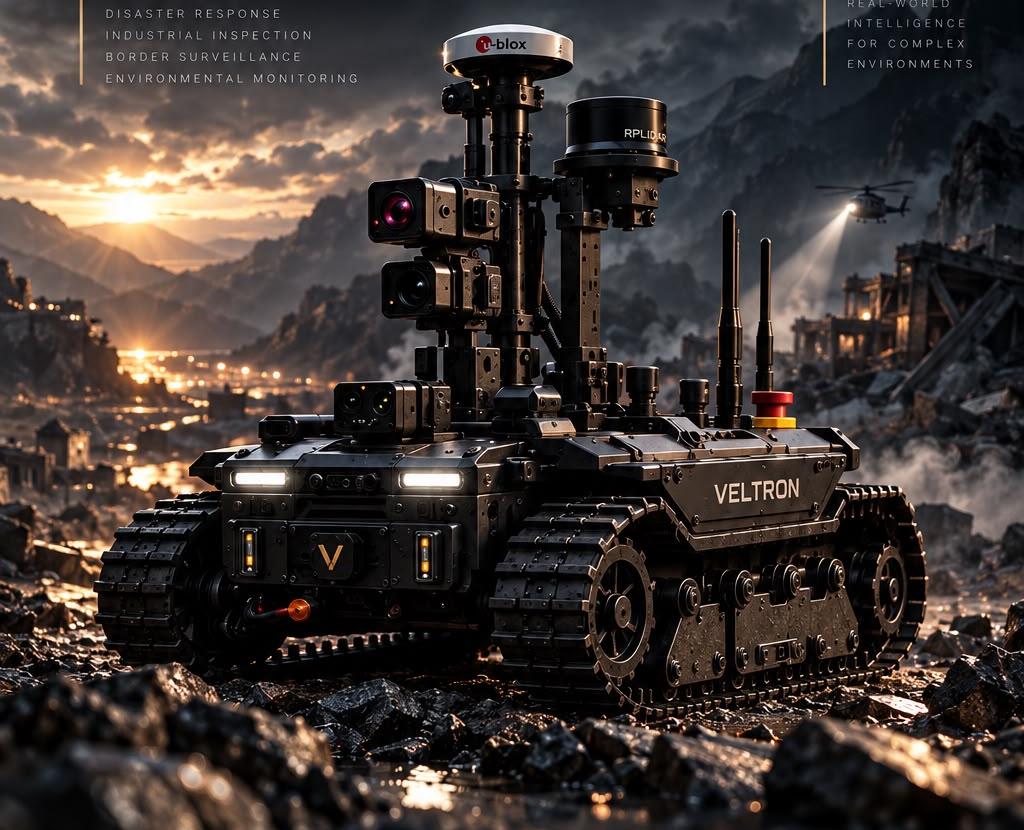
VELTRON UNIT X1 — Field Operations Key Visual
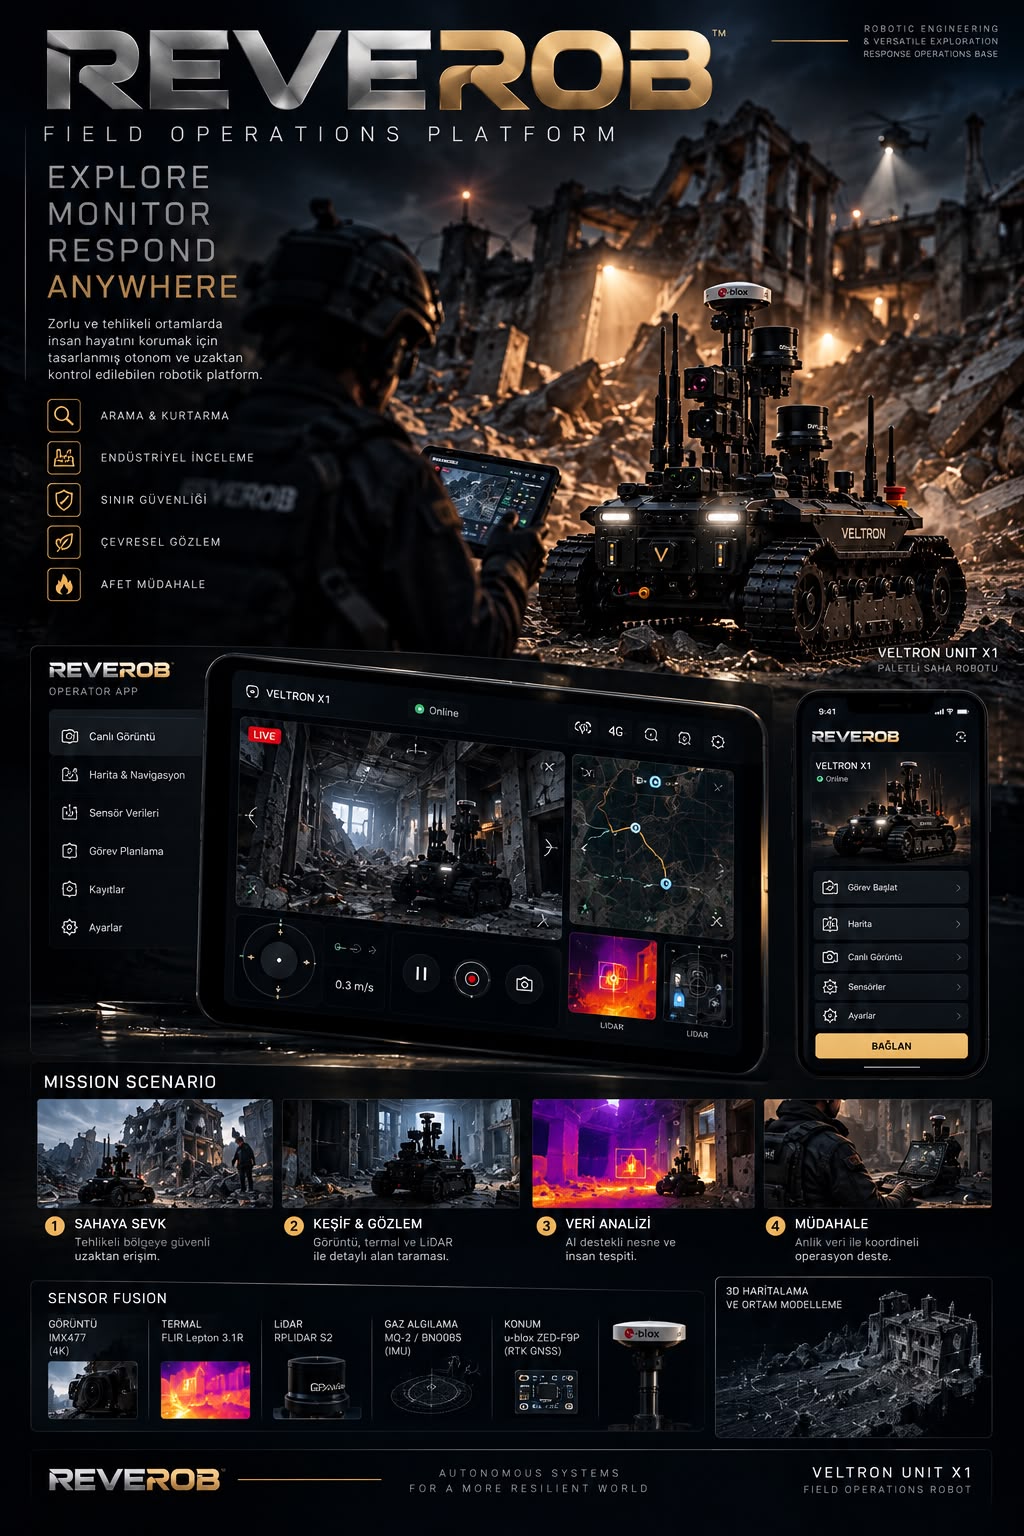
VELTRON UNIT X1 — Operator App & Sensor Fusion Poster
VELTRON E-UNIT X1 (Fire Edition) — 3-Layer Operational Architecture
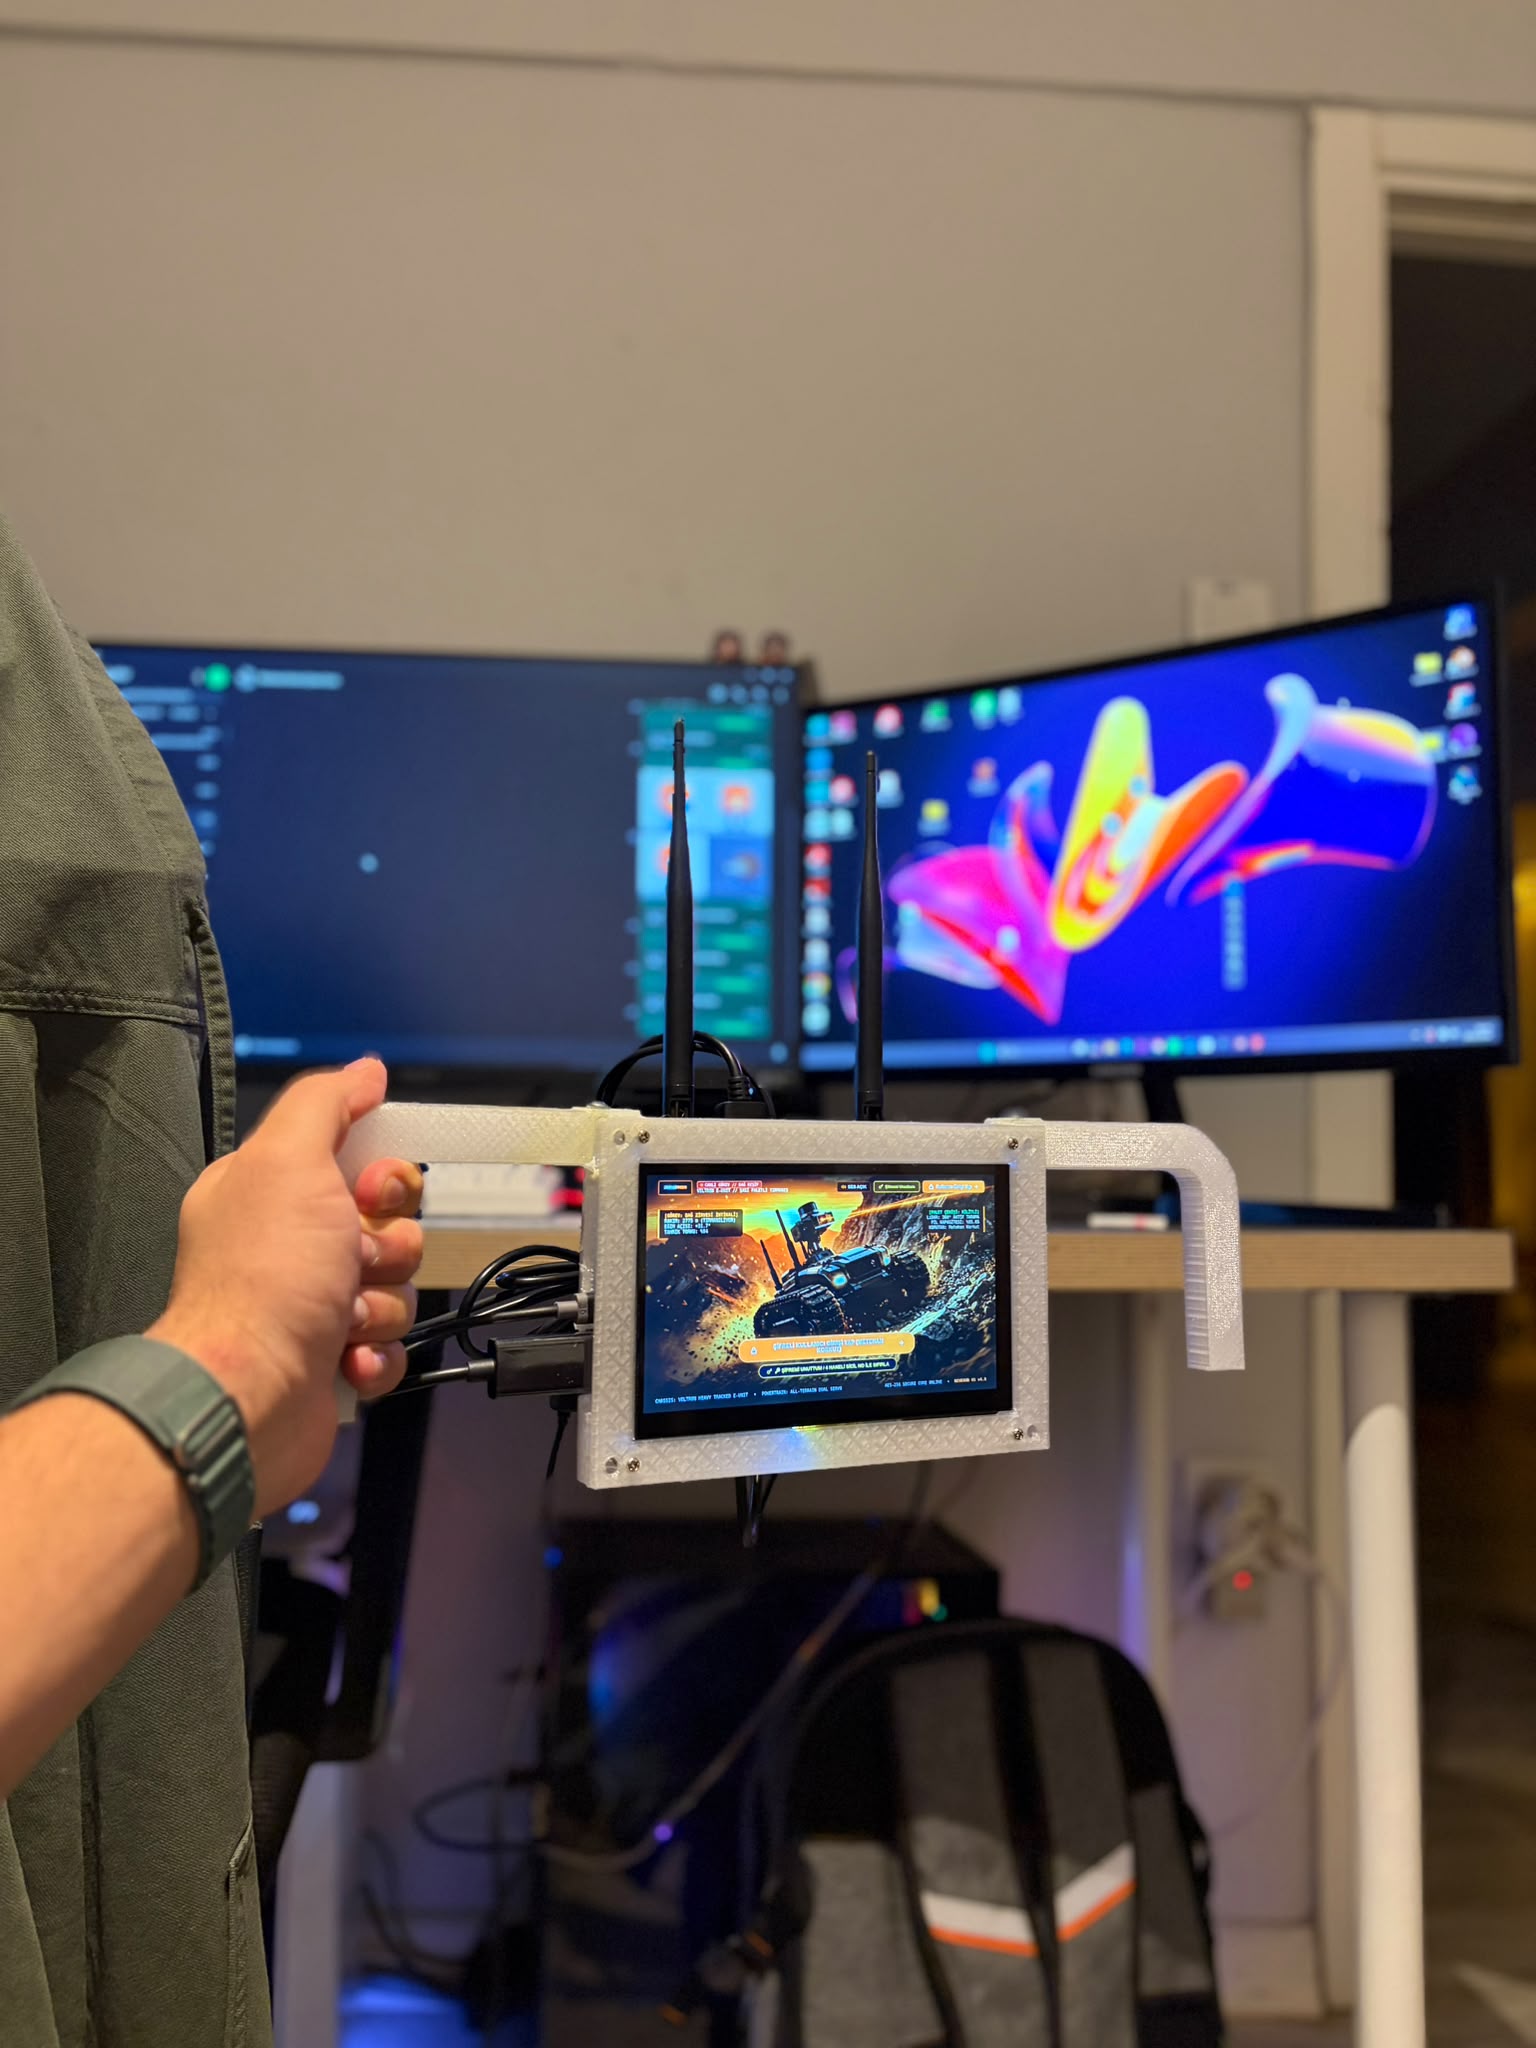
VELTRON Handheld Ground Control Station (GCS) Hardware Prototype
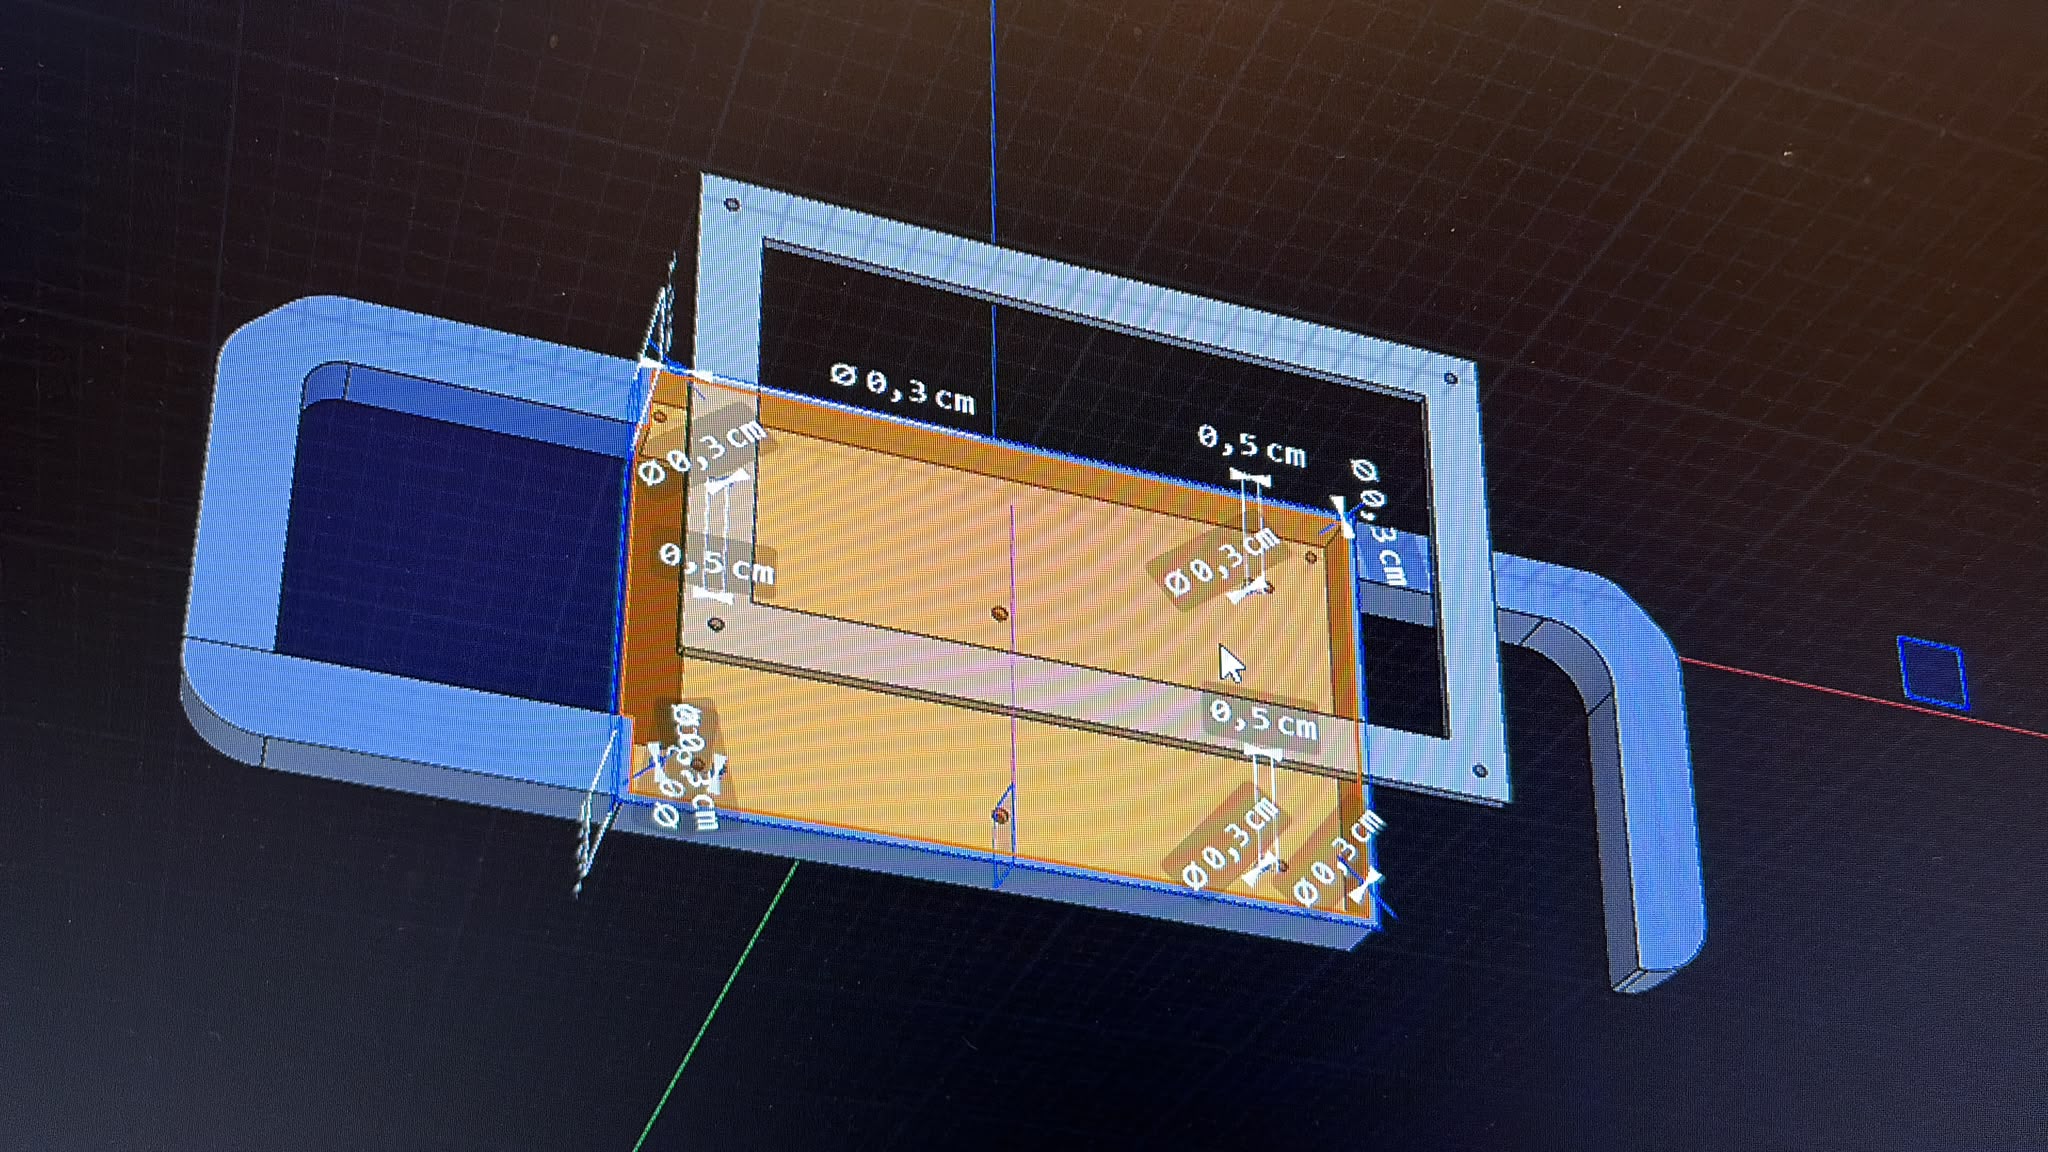
Controller Enclosure 3D CAD Modeling (Ø 0.3 cm / 0.5 cm)
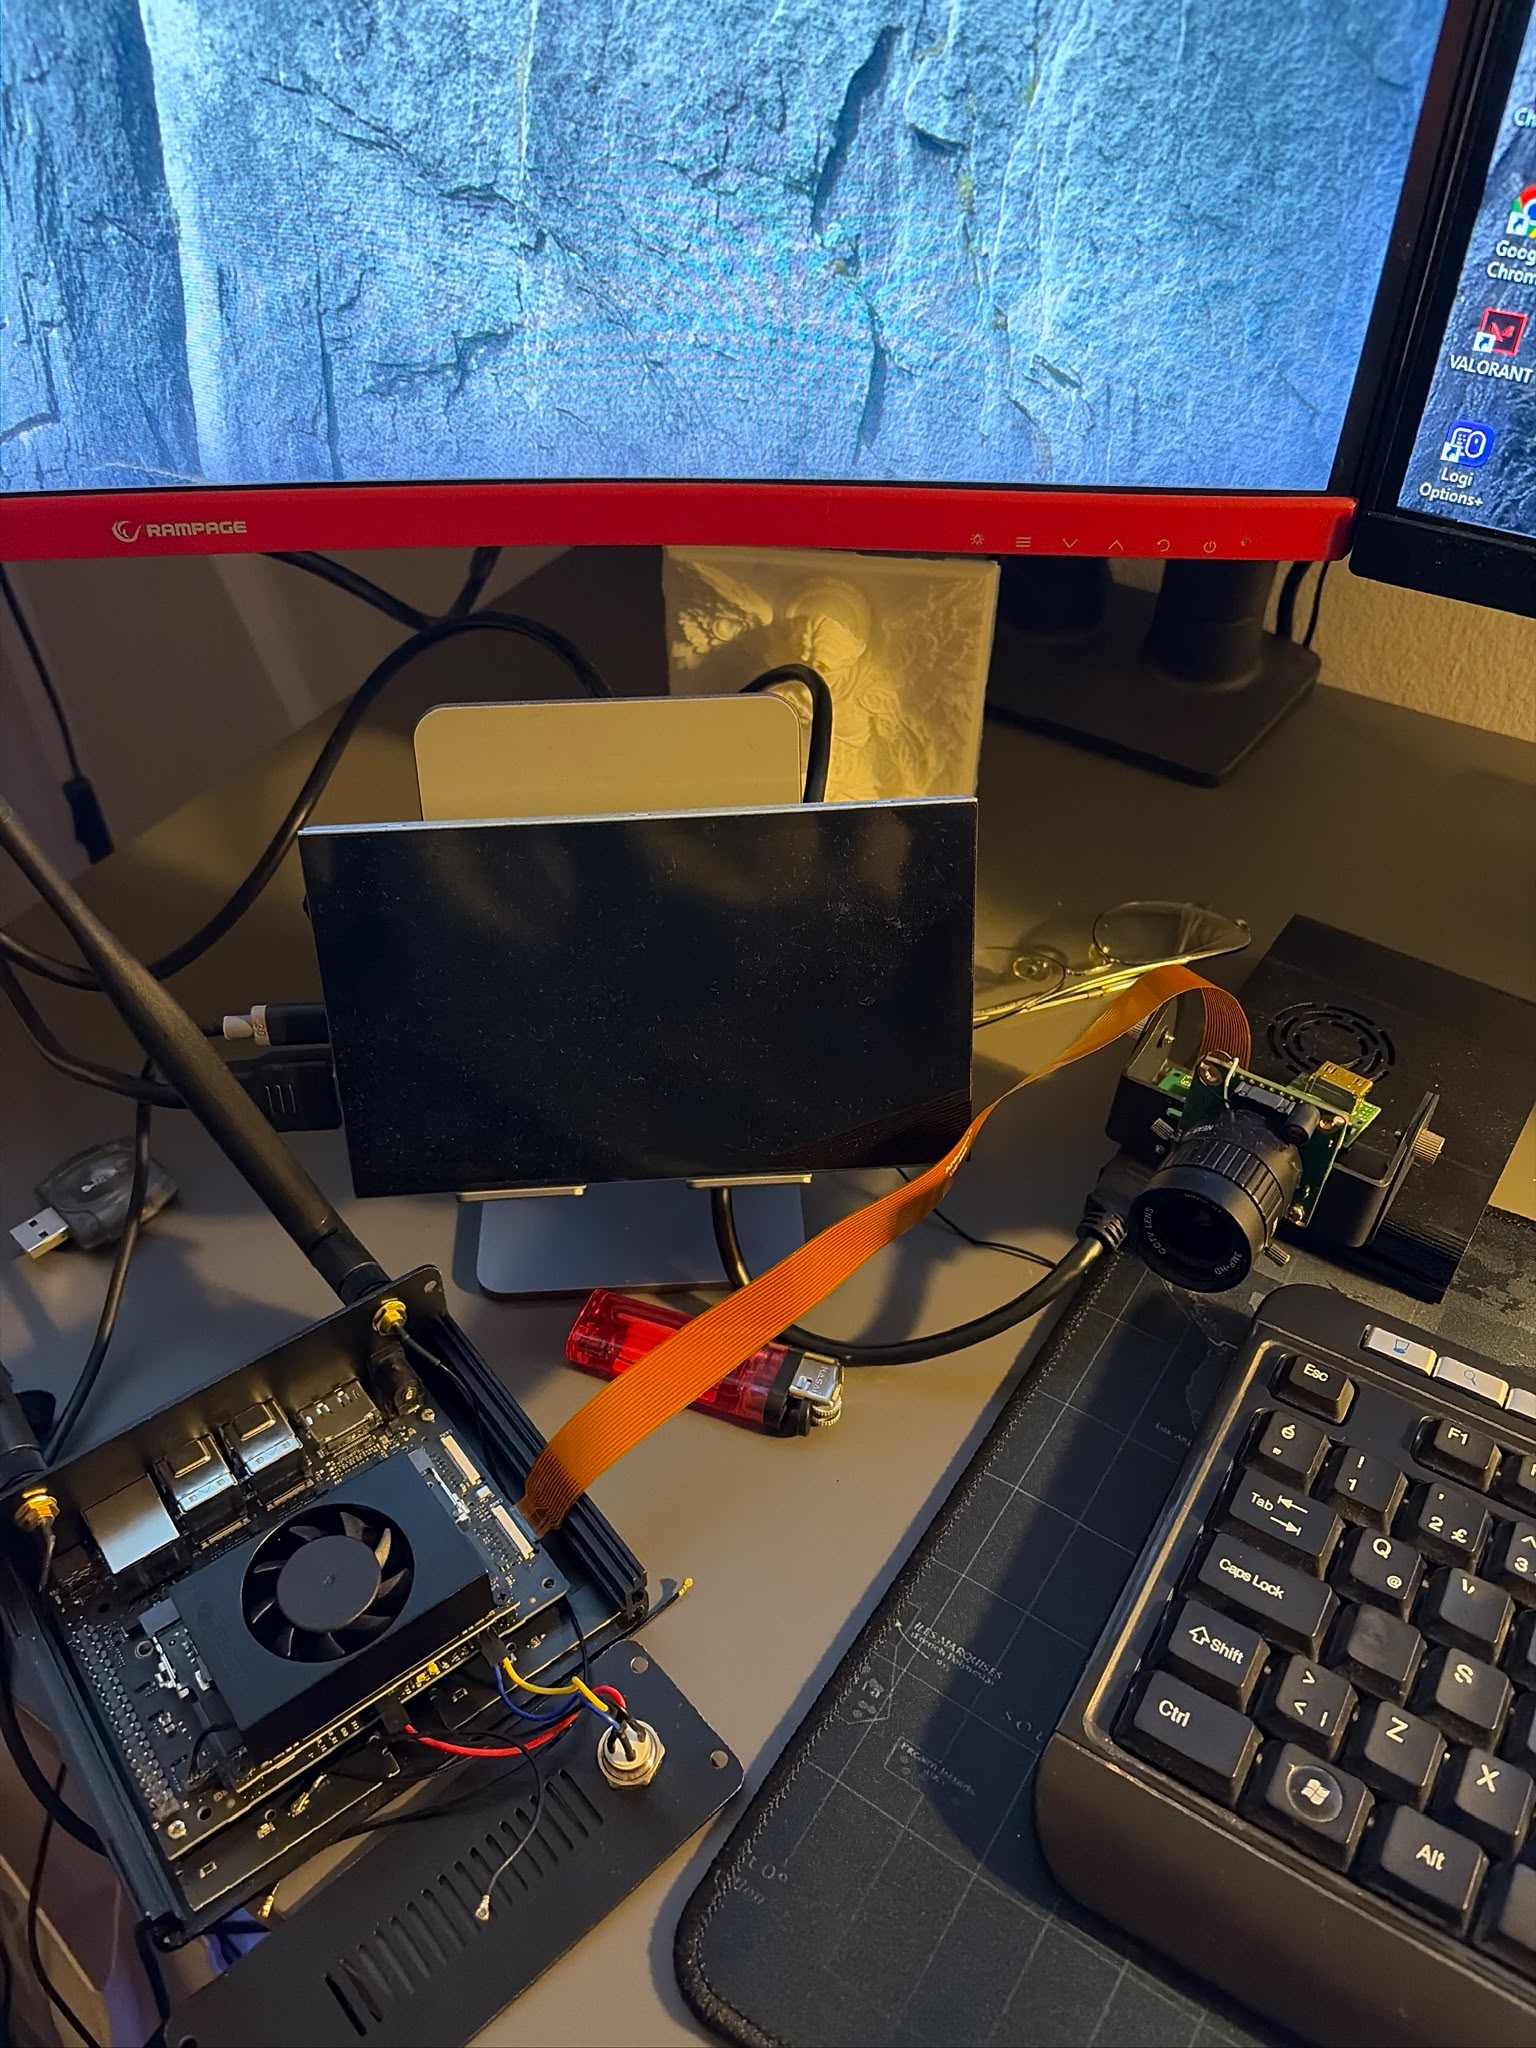
Embedded SBC, CSI Camera & 7-Inch IPS Display Testbench
VELTRON 3D Fabricated Physical Lab Signage
Wall-Mounted VELTRON Studio Identity Signage
RELATED TECHNOLOGIES & PLATFORMS
REVEROB OS & UPDATE CENTER
Explore the central command, YOLOv8 vision engine, and OTA update platform designed for VELTRON UNIT X1.
ENGINEERING LAB
Inspect the complete hardware ecosystem including Raspberry Pi 5, Jetson Orin Nano, IMX477, AMG8833, TFmini-S, and MQ-2.
R&D METHODOLOGY
Discover the 7-stage engineering process from VELTRON chassis drafting to handheld controller prototyping.